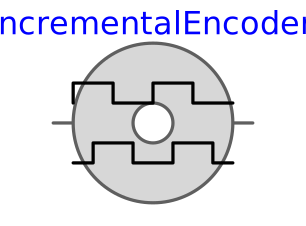
modelIncrementalEncoder
Incremental encoder
Extends from Modelica.Mechanics.Rotational.Interfaces.PartialOneFlangeAndSupport (Partial model for a component with one rotational 1-dim. shaft flange and a support used for graphical modeling, i.e., the model is build up by drag-and-drop from elementary components).
Information
This is a model of an incremental encoder.
It senses the angle of the flange phi (w.r.t. the optional support), providing 3 Boolean signals:
- 0-track
y[1]= 1 pulse per revolution with a length of2*pi/(4*pRev) - A-track
y[2]=pRevpulses per revolution - B-track
y[3]=pRevpulses per revolution, displaced by2*pi/(4*pRev)
It is used to measure angular velocity of electric drives, using block EncoderTimeSpan or EncoderPulseCount.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useSupport (from PartialOneFlangeAndSupport) | false | = true, if support flange enabled, otherwise implicitly grounded |
| Integer | pRev | Pulses per revolution |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Flange_b | flange (from PartialOneFlangeAndSupport) | Flange of shaft | |
| Support | support (from PartialOneFlangeAndSupport) | Support/housing of component | |
| Modelica.Blocks.Interfaces.BooleanOutput[3] | y | Encoder signals |
Components
| Type | Name | Default | Description |
|---|---|---|---|
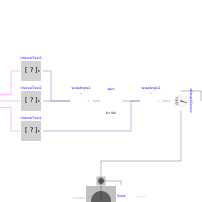
| Modelica.Mechanics.Rotational.Sensors.RelAngleSensor | relAngleSensor | ||
| Modelica.Blocks.Math.WrapAngle | wrapAngle1 | ||
| Modelica.Blocks.Math.Gain | gain | ||
| ToMSL.IntervalTest | intervalTest1 | ||
| ToMSL.IntervalTest | intervalTest2 | ||
| ToMSL.IntervalTest | intervalTest3 | ||
| Modelica.Blocks.Math.WrapAngle | wrapAngle2 |