blockEncoderPulseCount
Extends from Modelica.Blocks.Interfaces.DiscreteBlock (Base class of discrete control blocks), BLDC.Interfaces.EncoderEvaluation (Partial evaluation of an incremental encoder).
Information
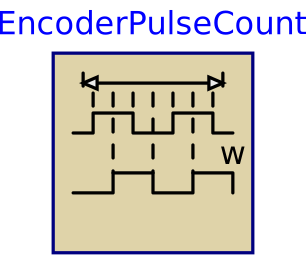
Evaluates the input signals from an IncrementalEncoder:
- 0-track
y[1]= 1 pulse per revolution with a length of2*pi/(4*pRev) - A-track
y[2]=pRevpulses per revolution - B-track
y[3]=pRevpulses per revolution, displaced by2*pi/(4*pRev)
and determines mechanical angular velocity w and mechanical angle phi:
- w = angular velocity
- phi = angle = integral of w
During the samplePeriod all rising and falling edges of A-track and B-track are counted.
The direction of rotation has to be detected by a logic from the values of A-track and B-track.
From that count, the angular velocity can be calculated: w=count*2*pi(4*pRev)/samplePeriod.
The accuracy of the result depends on the number of pulses per revolution and the samplePeriod.
Note that the output is discrete w.r.t. to time, it is not differentiable.
The algorithm depends on interrupts (which appear in Modelica as when-clauses).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Time | samplePeriod (from DiscreteBlock) | Sample period of component | |
| SI.Time | startTime (from DiscreteBlock) | 0 | First sample time instant |
| Integer | pRev (from EncoderEvaluation) | Pulses per revolution | |
| Modelica.Units.SI.Angle | phi0 (from EncoderEvaluation) | 0 | Initial mechanical angle (zero position) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.BooleanInput[3] | u (from EncoderEvaluation) | Encoder signals | |
| Modelica.Blocks.Interfaces.RealOutput | w (from EncoderEvaluation) | Mechanical angular velocity | |
| Modelica.Blocks.Interfaces.RealOutput | phi (from EncoderEvaluation) | Mechanical angle |