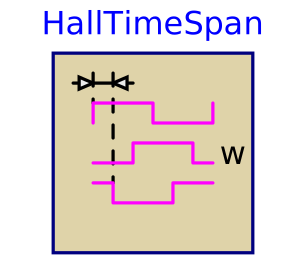
blockHallTimeSpan
Extends from Modelica.Blocks.Icons.DiscreteBlock (Graphical layout of discrete block component icon).
Information
Evaluates the input signals from a HallSensor: a 180°-rectangle per phase (per pole pair)
and determines electrical angular velocity w and electrical angle phi:
- w = angular velocity
- phi = angle = integral of w
The time span from one edge of the input signals to the next is measured, thus calculating the speed of rotation: 2*pi/(p*2*m)/(time - t0).
Taking both rising and falling edges into account, p*2*m edges per revolution are observed.
Note that the output is discrete w.r.t. to time, it is not differentiable.
The algorithm depends on interrupts (which appear in Modelica as when-clauses).
The direction of rotation has to be detected by a logic from the sequence of the Hall signals.
Note that this algorithm depends on the accuracy of the representation of time,
but usually gives better results than counting edges during a time gate.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | p | Number of pole pairs | |
| Integer | m | 3 | Number of stator phases |
| SI.Angle[m] | orientation | Modelica.Electrical.Polyphase.Functions.symmetricOrientation(m) | Orientation of phases |
| SI.Angle | phi0 | 0 | Initial mechanical angle (zero position) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.BooleanInput[m] | uC | Hall signals | |
| Modelica.Blocks.Interfaces.RealOutput | w | Mechanical anglar velocity | |
| Modelica.Blocks.Interfaces.RealOutput | phi | Mechanical angle |