modelPIDWithResetScale
Test model for PID controller with reset and scaling of the control error
Information
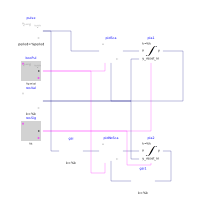
Validation test for the block Buildings.Controls.OBC.CDL.Reals.PIDWithReset with and without setting of the parameter that scales the control error.
The test has two combinations of a PID controller and a plant.
In PIDSca, the control error is scaled inside the controller, whereas
in the configuration that has PIDNoSca, the setpoint signal and the
measurement signal is scaled outside of the controller.
Both controllers and plants have the same trajectory, thereby validating that
the scaling is implemented correctly.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Reals.Sources.Pulse | pulse | Setpoint | |
| Buildings.Controls.OBC.CDL.Reals.PIDWithReset | pidSca | PID controller with scaling of control input | |
| Buildings.Controls.OBC.CDL.Reals.IntegratorWithReset | pla1 | Plant model | |
| Reals.Sources.Constant | resVal | Reset value | |
| Logical.Sources.Constant | resSig | Reset signal | |
| Buildings.Controls.OBC.CDL.Reals.PIDWithReset | pidNoSca | PID controller without scaling of control input | |
| Buildings.Controls.OBC.CDL.Reals.MultiplyByParameter | gai | Gain to scale setpoint | |
| Buildings.Controls.OBC.CDL.Reals.MultiplyByParameter | gai1 | Gain to scale measured value | |
| Buildings.Controls.OBC.CDL.Reals.IntegratorWithReset | pla2 | Plant model | |
| Logical.Sources.Pulse | booPul | Pulse for controller reset |
Revisions
-
October 15, 2020, by Michael Wetter:
First implementation.
This is for Buildings, issue 2182.