blockPIGain
Identify the control gain of a PI controller
Information
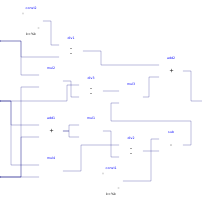
This block calculates the control gain of a PI model as
k = 0.15/kp + (0.35-LT/(L+T)2)(T/kp/L),
where kp is the gain of the first-order plus time-delay (FOPTD) model,
T is the time constant of the FOPTD model, and
L is the time delay of the FOPTD model.
References
Garpinger, Olof, Tore Hägglund, and Karl Johan Åström (2014) "Performance and robustness trade-offs in PID control." Journal of Process Control 24.5 (2014): 568-577.
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | kp | Gain of a first-order plus time-delay (FOPTD) model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | T | Time constant of the FOPTD model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | L | Time delay of the FOPTD model | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | k | Control gain |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.