blockGain
Identify the gain of a first-order plus time-delay model
Information
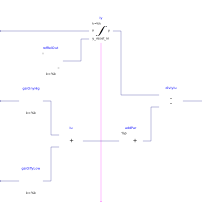
This block calculates the gain of a first-order plus time-delay model.
k = Iy/Iu,
Iy is calculated by
Iy = ∫ u(t) dt;
where u(t) is the relay output at t (see details in Buildings.Controls.OBC.Utilities.PIDWithAutotuning.Relay.Controller).
Iu is calculated by
Iu = ton yhig - toffylow,
where yhig and ylow are constants related to an asymmetric relay output. ton and toff are the length of the on period and the off period of the same asymmetric relay output, respectively.
References
J. Berner (2017). "Automatic Controller Tuning using Relay-based Model Identification." Department of Automatic Control, Lund University.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | yHig | Higher value for the output (assuming the reference output is 0) | |
| Real | yLow | Lower value for the output (assuming the reference output is 0) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | u | Relay controller output, (measurement - setpoint) | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | tOn | Length for the on period | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | tOff | Length for the off period | |
| Buildings.Controls.OBC.CDL.Interfaces.BooleanInput | triSta | Relay tuning status, true if the tuning starts | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | k | Gain |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.