blockTimeConstantDelay
Calculate the time constant and the time delay of a first-order plus time-delay model
Information
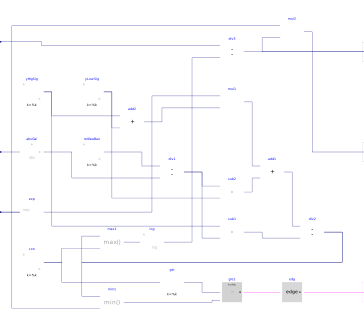
This block calculates the time constant and the time delay of a first-order plus time-delay (FOPTD) model.
Main equations
The time constant, T, is calculated by
T = ton/(ln((δ/|k|-yhig+exp(τ/(1 - τ))(yhig + ylow))/(yhig-δ/|k|))),
where yhig and ylow are constants related to
an asymmetric relay output.
ton is the length of the on period of the same asymmetric relay output.
δ is the dead band of the same asymmetric relay output.
k is the gain of this FOPTD model.
τ is the normalized time delay.
The time delay, L, is calculated by
L = T τ/(1 - τ),
References
J. Berner (2017). "Automatic Controller Tuning using Relay-based Model Identification." Department of Automatic Control, Lund University.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | yHig | Higher value for the output (assuming the reference output is 0) | |
| Real | yLow | Lower value for the output (assuming the reference output is 0) | |
| Real | deaBan | Deadband for holding the output value |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | tOn | Length for the on period | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | k | Gain | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | rat | Ratio between the time constant and the time delay | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | T | Time constant | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | L | Time delay | |
| Buildings.Controls.OBC.CDL.Interfaces.BooleanOutput | triFai | True when an error occurs in the autotuning process |
Revisions
-
March 8, 2024, by Michael Wetter:
Changed deadband to be consistent within the package. -
June 1, 2022, by Sen Huang:
First implementation.