
modelReverseActingPIDWithFirstOrderAMIGO
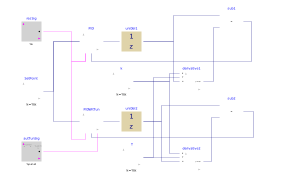
Information
Validation test for the block Buildings.Controls.OBC.Utilities.PIDWithAutotuning.FirstOrderAMIGO.
This example compares the output of an autotuning PID controller (PIDWitTun)
to that of a normal PID controller (PID) with prescribed gains.
Both PID controllers are connected with a first-order control process. At the beginning (0s-500s), the outputs from those two PID controllers are identical as their prescribed gains are the same.
Once the autotuning starts at 500s, the outputs of the two PID controllers
become different.
After the tuning completes, under the control of PIDWitTun, the value
of the controlled variable
is close to the setpoint after the tuning period ends (PIDWitTun.resPro.triEnd = true).
On the contrary, PID has a poor control performance,
i.e., the value of the controlled variable oscillates.
The example also shows that the autotunning process can be re-triggered
when the input triTun becomes true.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | SetPoint | Setpoint value | |
| Buildings.Controls.OBC.Utilities.PIDWithAutotuning.FirstOrderAMIGO | PIDWitTun | PID controller with an autotuning feature | |
| Buildings.Controls.OBC.CDL.Reals.PIDWithReset | PID | PID controller with constant gains | |
| Buildings.Controls.OBC.CDL.Logical.Sources.Constant | resSig | Reset signal | |
| Buildings.Controls.OBC.CDL.Discrete.UnitDelay | uniDel2 | A delay process for control process 2 | |
| Buildings.Controls.OBC.CDL.Discrete.UnitDelay | uniDel1 | A delay process for control process 1 | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | k | Gain of the first order process | |
| Buildings.Controls.OBC.CDL.Reals.Sources.Constant | T | Time constant of the first order process | |
| Buildings.Controls.OBC.CDL.Reals.Subtract | sub1 | A subtract block that is used to mimic the first order process 1 | |
| Buildings.Controls.OBC.CDL.Reals.Subtract | sub2 | A subtract block that is used to mimic the first order process 2 | |
| Buildings.Controls.OBC.CDL.Reals.Derivative | derivative1 | A derivative block that is used to mimic the first order process 1 | |
| Buildings.Controls.OBC.CDL.Reals.Derivative | derivative2 | A derivative block that is used to mimic the first order process 2 | |
| Buildings.Controls.OBC.CDL.Logical.Sources.Pulse | autTunSig | Signal for enabling the autotuning |
Revisions
-
June 1, 2022, by Sen Huang:
First implementation.