blockPIDWithEnable
PID controller with enable signal
Extends from Modelica.Blocks.Icons.Block (Basic graphical layout of input/output block).
Information
Controller that is identical to Buildings.Controls.OBC.CDL.Reals.PIDWithReset, except that it has an enable input signal that can be used to deactivate the PID output and instead output a constant signal.
-
When the input
uEnaswitches totrue, the integral term of the PID controller is reset so that the output is equal toy_reset, and afterwards this controller will produce at its outputythe output of the PID controller. -
When the input
uEna=false, the output of the controller is set toy_neutraland the setpoint is overridden by the measurement signal in order to avoid time integration of the control error.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Types.SimpleController | controllerType | Buildings.Controls.OBC.CDL.Types.SimpleController.PI | Type of controller |
| Real | r | 1 | Typical range of control error, used for scaling the control error |
| Boolean | reverseActing | true | Set to true for reverse acting, or false for direct acting control action |
| Real | y_reset | yMin | Value to which the controller output is reset if the boolean trigger has a rising edge |
| Real | y_neutral | y_reset | Value to which the controller output is reset when the controller is disabled |
| Control gains | |||
| Real | k | 1 | Gain of controller |
| Real | Ti | 0.5 | Time constant of integrator block |
| Real | Td | 0.1 | Time constant of derivative block |
| Limits | |||
| Real | yMax | 1 | Upper limit of output |
| Real | yMin | 0 | Lower limit of output |
| Advanced › Integrator anti-windup | |||
| Real | Ni | 0.9 | Ni*Ti is time constant of anti-windup compensation |
| Advanced › Derivative block | |||
| Real | Nd | 10 | The higher Nd, the more ideal the derivative block |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | u_s | Setpoint input signal | |
| Buildings.Controls.OBC.CDL.Interfaces.RealInput | u_m | Measurement input signal | |
| Buildings.Controls.OBC.CDL.Interfaces.BooleanInput | uEna | Enable signal. If true, PID is active and y will be equal to the PID output, otherwise y will be y_neutral | |
| Buildings.Controls.OBC.CDL.Interfaces.RealOutput | y | Control output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
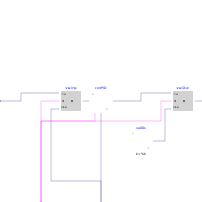
| Buildings.Controls.OBC.CDL.Reals.PIDWithReset | conPID | PID controller | |
| Buildings.Controls.OBC.CDL.Reals.Switch | swiInp | Switch to select input signal | |
| Buildings.Controls.OBC.CDL.Reals.Switch | swiOut | Switch to select output signal |
Revisions
-
November 15, 2025, by Michael Wetter:
Moved toBuildings.Controls.OBC.Utilities.PIDWithEnableas there were identical implementations inBuildings.DHCand inBuildings.Templates. -
March 29, 2024, by Antoine Gautier:
First implementation.