modelIdealMotor
Ideal motor model with hysteresis
Extends from Modelica.Blocks.Interfaces.SISO (Single Input Single Output continuous control block).
Information
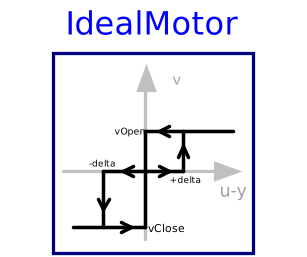
Ideal actuator motor model with hysteresis and finite actuation speed.
If the current actuator position y is below (or above) the
input signal u by an amount bigger than the hysteresis
delta, then the position y is increased (decreased)
until it reaches u.
The output y is bounded between 0 and 1.
Note: This model can introduce state events which increase the computation time.
For a more efficient implementation that approximates a motor, set in
the valve or damper model the parameter use_strokeTime=true
instead of using this motor model.
See also
Buildings.Fluid.Actuators.UsersGuide.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | delta | 0.05 | Hysteresis |
| Modelica.Units.SI.Time | tOpe | 120 | Opening time |
| Modelica.Units.SI.Time | tClo | tOpe | Closing time |
| Real | y_start | 0.5 | Start position |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
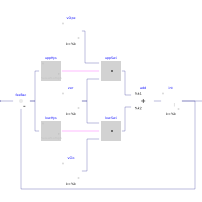
| Modelica.Blocks.Logical.Hysteresis | uppHys | ||
| Modelica.Blocks.Logical.Hysteresis | lowHys | Lower hysteresis | |
| Modelica.Blocks.Logical.Switch | uppSwi | ||
| Modelica.Blocks.Continuous.LimIntegrator | int | Integrator for valve opening position |
Revisions
-
March 24, 2017, by Michael Wetter:
RenamedfilteredInputtouse_inputFilter.
This is for #665. -
September 8, 2008 by Michael Wetter:
Added to instanceintthe attributey(stateSelect=StateSelect.always). Without this attribute, the model Buildings.Fluid.Examples.TwoWayValves setsy=3which is consistent with this model. -
September 8, 2008 by Michael Wetter:
First implementation.