modelPhysicalModel
Rikitake system
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
See documentation of the enclosing subpackage.
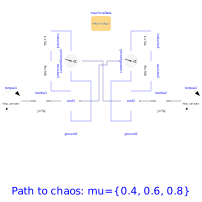
The experiment could be implemented in reality by two series excited DC machines, using the negative armature current of the other machine as excitation current. Unfortunately two torque sources (current controlled electric drives) are needed.
Note
When defining different machine parameters, the dynamics of the machines and therefore the time scaling machineData.tRef
defined by mechanical and electrical time constant will change and it might be necessary to adapt StopTime and Interval in the experiment annotation.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | mu | 0.4 | Resistive parameter |
| Real | D | 2 | Speed difference |
| MachineData | machineData |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | x1 | emf1.i/machineData.iRef | Current 1 |
| Real | x2 | emf2.i/machineData.iRef | Current 2 |
| Real | z | emf1.w/machineData.wRef | Speed |
| Components.RotationalEMF | emf1 | ||
| Components.RotationalEMF | emf2 | ||
| Modelica.Electrical.Analog.Basic.Resistor | resistor1 | ||
| Modelica.Electrical.Analog.Basic.Inductor | inductor1 | ||
| Modelica.Electrical.Analog.Basic.Inductor | inductor2 | ||
| Modelica.Electrical.Analog.Basic.Resistor | resistor2 | ||
| Modelica.Electrical.Analog.Basic.Ground | ground1 | ||
| Modelica.Electrical.Analog.Basic.Ground | ground2 | ||
| Modelica.Mechanics.Rotational.Components.Inertia | inertia1 | ||
| Modelica.Mechanics.Rotational.Components.Inertia | inertia2 | ||
| Modelica.Mechanics.Rotational.Sources.ConstantTorque | torque1 | ||
| Modelica.Mechanics.Rotational.Sources.ConstantTorque | torque2 | ||
| Modelica.Electrical.Analog.Sensors.CurrentSensor | currentSensor1 | ||
| Modelica.Electrical.Analog.Sensors.CurrentSensor | currentSensor2 |