
modelCloth_Initialization_2
Cloth initialization example
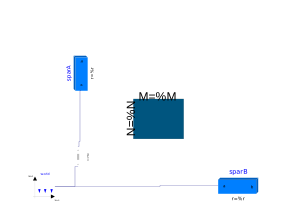
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Copyright © 2018
ATA ENGINEERING, INC.
ALL RIGHTS RESERVED
Example using the cloth modeling framework with a blanket hanging between a fixed spar and a hinged spar starting at a relative angle of 25 degrees to each other. Gravity acting on the blanket pulls the spars together.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | M | 3 | |
| Integer | N | 4 | |
| SI.Length | length | 2 | |
| SI.Length | width | 1 | |
| SI.Length | length_start | 1 | |
| Real | angle | 25 | Start angle in degrees |
| SI.Position[3] | P1 | {0.1, 0.1, 0} | |
| SI.Position[3] | P2 | {1.1, 0.1, 0} | |
| SI.Position[3] | P3 | {1.1, 0, 0} | |
| SI.Position[3] | P4 | {0.1, 0, 0} | |
| SI.Position[3] | P1_start | {0.1*cos(angle*3.14/180), 0.1*sin(angle*3.14/180), 0} | Initial location of P1 in world coordinates |
| SI.Position[3] | P2_start | {1.1*cos(angle*3.14/180), 1.1*sin(angle*3.14/180), 0} | Initial location of P2 in world coordinates |
| SI.Position[3] | P3_start | {1.1, 0, 0} | Initial location of P3 in world coordinates |
| SI.Position[3] | P4_start | {0.1, 0, 0} | Initial location of P4 in world coordinates |
| Properties.ClothProperty | clothProps |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.World | world | ||
| DeployStructLib.DSL_Globals | DSLglb | ||
| DeployStructLib.Parts.Cloth.cloth | cloth1 | ||
| Modelica.Mechanics.MultiBody.Parts.BodyBox | sparA | ||
| Modelica.Mechanics.MultiBody.Parts.BodyBox | sparB | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | revolute |