modelcontrolModule_SynchronousPower
Information
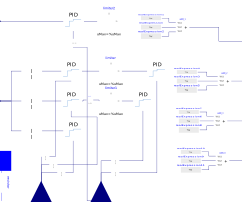
This is a PID controller using the Modelica Synchronous library to model the PID blocks. It has inputs that account for the dictated position of the quadcopter and yaw. It compares the actual XYZ position of the quadcopter to the commanded XYZ position and controls the current applied to each of the motors as a result.
This controller has an electrical input to estimate the power consumption.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Time | samplePeriod | 0.01 | |
| Real | maxTilt | 2 | Upper limits of input signals |
| Modelica.Units.SI.Resistance | R | R | Internal resistance of controller |
| Modelica.Units.SI.Voltage | V | V | Voltage of the controller |
| Yaw PID | |||
| Real | Yaw_ki | 0 | I gain for yaw |
| Real | Yaw_kd | 0.08 | D gain for yaw |
| Real | Yaw_kp | 0.04 | P gain for yaw |
| X position PID | |||
| Real | x_ki | 0.03 | I gain for x position |
| Real | x_kd | 0.1 | D gain for x position |
| Real | x_kp | 0.1 | P gainfor x position |
| Y position PID | |||
| Real | y_ki | 0.03 | I gain for y position |
| Real | y_kd | 0.1 | D gain for y position |
| Real | y_kp | 0.1 | P gain for y position |
| Z position PID | |||
| Real | z_ki | 1 | I gain for z position |
| Real | z_kd | 0.8 | D gain for z position |
| Real | z_kp | 1.5 | P gain for z position |
| Gyroscope PID | |||
| Real | gyro_x_ki | 0.3 | I gain for gyroscope measurements in the x direction |
| Real | gyro_x_kd | 1 | D gain for the gyroscope measurements in the x direction |
| Real | gyro_x_kp | 1 | P gain for the gyroscope measurements in the x dire3ction |
| Real | gyro_y_ki | 0.1 | I gain for the gyroscope measurements in the y direction |
| Real | gyro_y_kd | 1 | D gain for the gyroscope measurements in the y direction |
| Real | gyro_y_kp | 1 | P gain for the gyroscope measurements in the y direction |