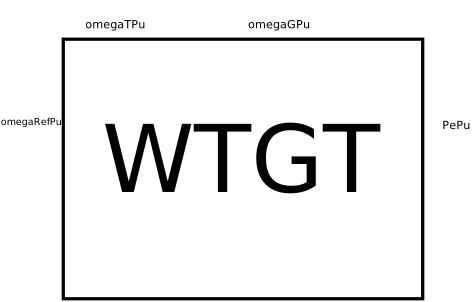
modelDriveTrainPmConstant
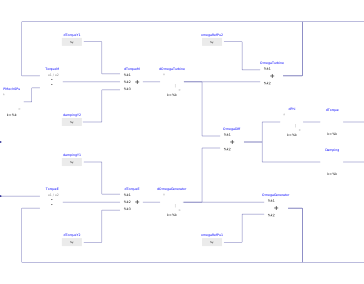
Extends from Dynawo.Electrical.Controls.WECC.Mechanical.BaseClasses.BaseDriveTrain (Drive Train Control Base Model).
Information
This block contains the drive train model for generic WECC WTG type 4 model according to (in case page cannot be found, copy link in browser):
https://www.wecc.org/Reliability/WECC-Second-Generation-Wind-Turbine-Models-012314.pdf
This model is a simplified model for the purpose of emulating the behavior of torsional mode oscillations. The shaft damping coefficient (Dshaft) in the drive-train model is fitted to capture the net damping of the torsional mode seen in the post fault electrical power response. In the actual equipment, the drive train oscillations are damped through filtered signals and active damping controllers, which obviously are significantly different from the simple generic two mass drive train model used here. Therefore, the parameters (and variables) of this simple drive-train model cannot necessarily be compared with actual physical quantities directly.
In this version A of the drive train, the mechanical power is set to be constant as per the initial electrical power.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Types.PerUnit | PInj0Pu (from BaseDriveTrain) | Initial value of mechanical power in pu (base SNom) | |
| Mechanical | |||
| Types.Time | Ht (from ParamsDriveTrain) | Turbine Inertia in s (typical: 5 s) | |
| Types.Time | Hg (from ParamsDriveTrain) | Generator Inertia in s (typical: 1 s) | |
| Types.PerUnit | Dshaft (from ParamsDriveTrain) | Damping coefficient in pu (typical: 1.5 pu, base SNom, omegaNom) | |
| Types.PerUnit | Kshaft (from ParamsDriveTrain) | Spring constant in pu (typical: 200 pu, base SNom, omegaNom) | |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | PePu (from BaseDriveTrain) | Electrical active power in pu (base SNom) | |
| Modelica.Blocks.Interfaces.RealInput | omegaRefPu (from BaseDriveTrain) | Reference frequency used for Generator and Turbine in pu (base omegaNom) | |
| Modelica.Blocks.Interfaces.RealOutput | omegaGPu (from BaseDriveTrain) | Generator frequency used for electrical control in pu (base omegaNom) | |
| Modelica.Blocks.Interfaces.RealOutput | omegaTPu (from BaseDriveTrain) | Turbine frequency in pu (base omegaNom) | |
| Modelica.Blocks.Interfaces.RealOutput | dTorqueY (from BaseDriveTrain) | Torque derivative in pu/s (base SNom, omegaNom) | |
| Modelica.Blocks.Interfaces.RealOutput | dampingY (from BaseDriveTrain) | Damping value in pu (base SNom, omegaNom) |