modelFirstEVAngle
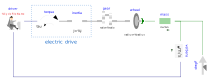
Simulates a very basic Electric Vehicle
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
Basic EV model with resistance to movement which includes slope.
Note that the model is only partially working since it is not able to stop the vehicle with negative angles when zero speed is needed.
Check the variable dragF.locked when the driver cycle is Sort1.txt: for t=80-100s the requested speed is zero, but the variable dragF.locked remains false.
Fixing this requires implementing a totally different driver's model, since the driver in these cases must explicitly push on the brake pedal, often requesting a strong negative torque. This enhanced driver model is out of the scope of the EHPTlib library.