blockControlLogic
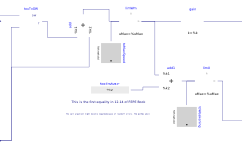
Follows upper fig. 12.15 from FEPE Book
Information
This class produces a three-phase voltage system to variable-frequency control of an asynchronous motor.
The output voltages constitute a three-phase system of quasi-sinusoidal shapes, created according to the following equations:
Wel=Wmecc*PolePairs+DeltaWel
U=U0+(Un-U0)*(Wel)/Wnom
where:
- U0, Un U, are initial, nominal and actual voltage amplitudes
- Wmecc, Wel are machine (mechanical) and supply (electrical) angular speeds
- PolePairs are the number of machine pole pairs
- DeltaWel is the difference between synchnonous angular speed and mechichal speed (divided by pole pairs). It is a non-linear function of the input torque.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Resistance | Rr | Rotor resistance | |
| Modelica.Units.SI.Resistance | Rs | Stator resistance | |
| Modelica.Units.SI.Voltage | uBase | Base phase-to-phase RMS voltage | |
| Modelica.Units.SI.AngularVelocity | weBase | 314.16 | Base electric frequency |
| Modelica.Units.SI.Inductance | Lstray | Combined stray inductance | |
| Modelica.Units.SI.AngularVelocity | wmMax | 314.16 | Maximum mechanical Speed |
| Integer | pp | number of pole pairs (Integer) | |
| Real | Kw | uBase/sqrt(3)/(weBase/pp) | Ratio U/Wmecc |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | Wm | ||
| Modelica.Blocks.Interfaces.RealOutput | Ustar | ||
| Modelica.Blocks.Interfaces.RealInput | Tstar | ||
| Modelica.Blocks.Interfaces.RealOutput | Westar |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Math.Add | add | ||
| Modelica.Blocks.Nonlinear.Limiter | limWm | ||
| ASMArelated.TorqueToDW | tauToDW | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Modelica.Blocks.Math.Add | add1 | ||
| Modelica.Blocks.Nonlinear.Limiter | limU | ||
| Modelica.Blocks.Logical.GreaterThreshold | toWeakening | ||
| Modelica.Blocks.Logical.GreaterThreshold | toMaxSpeed | ||
| Modelica.Blocks.Sources.RealExpression | toIstar |