modelMTPAalExperimental
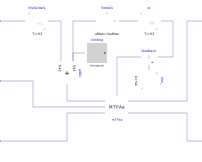
MTPA logic for an anisotropic PMSM machine with current limitation
Information
This is an experimental version used only for SmaALlSpeeds. Operation of PI controller not well calibrated for all applications, since it lacks antiwindup.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Time | integTime | 2 | |
| Real | gain | 5000/(1.5*Ipm*pp) | Current loop gain |
| Modelica.Units.SI.Current | Ipm | 1.5 | Permanent magnet current |
| Integer | pp | 1 | Pole pairs |
| Modelica.Units.SI.Resistance | Rs | 0.02 | Stator resistance |
| Modelica.Units.SI.Inductance | Ld | 0.4 | Basic direct-axis inductance |
| Modelica.Units.SI.Inductance | Lq | 1.1 | Basic quadrature-axis inductance |
| Modelica.Units.SI.Voltage | Umax | 100 | Max rms voltage per phase to the motor |
| Modelica.Units.SI.Current | Ilim | 100 | nominal current (rms per phase) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | torqueReq | ||
| Modelica.Blocks.Interfaces.RealInput | wMech | ||
| Modelica.Blocks.Interfaces.RealOutput | Id | ||
| Modelica.Blocks.Interfaces.RealOutput | Iq | ||
| Modelica.Blocks.Interfaces.RealInput | uDC | DC voltage |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| MTPAa | mTPAa | ||
| Modelica.Blocks.Math.Feedback | feedback | ||
| Modelica.Blocks.Sources.Constant | Ilim_ | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter1 | ||
| Modelica.Blocks.Math.Add | add1 | ||
| Modelica.Blocks.Continuous.FirstOrder | firstOrder1 | ||
| Modelica.Blocks.Logical.GreaterThreshold | limiting | ||
| Modelica.Blocks.Continuous.PI | pi |