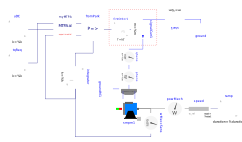
modelSmaAllSpeeds

Information

Permanent magnet synchronous machine drive with MTPA control specifically designed for isotropic machines.

Initially the transient has low speed and no Id is needed: the control chose therefore Id=0.

Later speed increases and the control logic requires a negative Id to control machine voltage.

Here control on current amplitude is implemented, which becomes active during the central part of the simulation; in this case only part of the requested toque is delivered.

Parameters

TypeNameDefaultDescription
RealUIpeaksqrt(2)*100

Components

TypeNameDefaultDescription
Modelica.Electrical.Analog.Basic.Groundground
Modelica.Electrical.Machines.BasicMachines.SynchronousMachines.SM_PermanentMagnetsmpm1
Modelica.Electrical.Machines.Utilities.TerminalBoxterminalBox1
Modelica.Electrical.Polyphase.Sources.SignalCurrentsignalCurr1
Modelica.Electrical.Polyphase.Basic.Starstar1
Modelica.Blocks.Sources.ConstantuDC
Modelica.Mechanics.Rotational.Sensors.SpeedSensorwMeccSens
Modelica.Blocks.Continuous.Integratorintegrator
EHPTlib.ElectricDrives.SMArelated.FromParkfromPark
Modelica.Electrical.Analog.Basic.GroundgroundM1
EHPTlib.ElectricDrives.SMArelated.MTPAalExperimentalmyMTPA
Modelica.Blocks.Continuous.FirstOrder[3]firstOrder1
Modelica.Blocks.Sources.ConstanttqReq
Modelica.Mechanics.Rotational.Sources.Speedspeed
Modelica.Blocks.Sources.Rampramp
Modelica.Electrical.Polyphase.Sensors.ReactivePowerSensorqSens
Modelica.Electrical.Polyphase.Sensors.AronSensorpSens
Modelica.Mechanics.Rotational.Sensors.PowerSensorpowMech