blockPropDriver
Simple Proportional controller driver
Information
Simple driver model.
It reads a reference cycle from a file then controls speed with a simple proportional feedback law.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| String | CycleFileName | "cycleName.txt" | Drive Cycle Name ex: "sort1.txt" |
| Real | k | Controller gain | |
| Real | yMax | 1.e6 | Max output value (absolute) |
| Modelica.Blocks.Types.Extrapolation | extrapolation | Modelica.Blocks.Types.Extrapolation.LastTwoPoints | Extrapolation of data outside the definition range |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | V | ||
| Modelica.Blocks.Interfaces.RealOutput | tauRef | ||
| Modelica.Blocks.Interfaces.RealOutput | accelTau | ||
| Modelica.Blocks.Interfaces.RealOutput | brakeTau |
Components
| Type | Name | Default | Description |
|---|---|---|---|
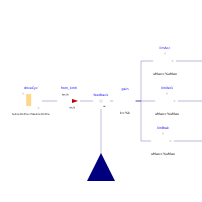
| Modelica.Blocks.Math.UnitConversions.From_kmh | from_kmh | ||
| Modelica.Blocks.Sources.CombiTimeTable | driveCyc | ||
| Modelica.Blocks.Math.Feedback | feedback | ||
| SupportModels.Miscellaneous.Gain | gain | ||
| Modelica.Blocks.Nonlinear.Limiter | limAcc | ||
| Modelica.Blocks.Nonlinear.Limiter | limBrak | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter1 |