modelDriverEnvironment
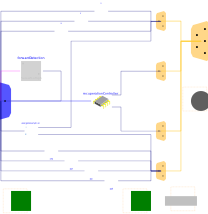
Extends from VehicleInterfaces.DriverEnvironments.Interfaces.Base (Basic interface definition for the driver-vehicle interface), VehicleInterfaces.Icons.DriverEnvironment (Icon for a driver environment subsystem).
Information
The driver environment communicates measured values from the sub-busses of the control bus to the driver interface, and the driver commands back from the driver interface to the sub-busses of the control bus.
Take care:
If used with a throttle and brake model, you have to set useDriverModel = false.
The throttle and brake model defines the direction of movement (forward/backward).
If used with a driver model, you have to set useDriverModel = true.
The direction of movement (forward/backward) is automatically detected from the bus signal vPreview.
The throttle and brake signals are sent to the brake system and the electric drive, depending on the the replaceable recuperation controller.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useDriverModel | Use driver model (otherwise throttle and brake)? | |
| Boolean | useRecuperation | true | Braking with recuperation, otherwise mechanical? |
| Real | SoCLo | 0.980 | Recuperate below SoCLo, above use mechanical brake |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| VehicleInterfaces.Interfaces.ControlBus | controlBus (from Base) | Control signal bus | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | chassisFrame (from Base) | Chassis reference frame (optional) | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | steeringWheel (from Base) | Steering wheel connection (optional) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | acceleratorPedal (from Base) | Accelerator pedal connection (optional) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | brakePedal (from Base) | Brake pedal connection (optional) | |
| Interfaces.DriverInterface | driverInterface |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Components.RecuperationController | recuperationController | ||
| Modelica.Blocks.Logical.Hysteresis | forwardDetection | ||
| Components.EnergyConsumption | energyConsumption |