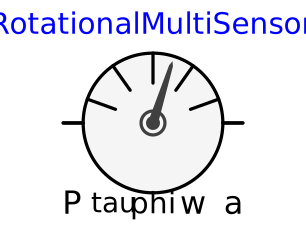
modelRotationalMultiSensor
Ideal sensor to measure the absolute acceleration, velocity, distance, force and power between two flanges
Extends from Modelica.Mechanics.Rotational.Interfaces.PartialRelativeSensor (Partial model to measure a single relative variable between two flanges).
Information
Measures the absolute position ,absolute velocity and absolute acceleration of a flange_a, the cut-force and power between two flanges in an ideal way and provides the results as output signals s, v, a, f and power, respectively.
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Flange_a | flange_a (from PartialRelativeSensor) | Left flange of shaft | |
| Flange_b | flange_b (from PartialRelativeSensor) | Right flange of shaft | |
| Modelica.Blocks.Interfaces.RealOutput | power | Power in flange as output signal | |
| Modelica.Blocks.Interfaces.RealOutput | tau | Torque in flange_a and flange_b (tau = flange_a.tau = -flange_b.tau) as output signal | |
| Modelica.Blocks.Interfaces.RealOutput | phi | Absolute angular positon of flange as output signal | |
| Modelica.Blocks.Interfaces.RealOutput | w | Absolute angular velocity of flange as output signal | |
| Modelica.Blocks.Interfaces.RealOutput | a | Absolute angular acceleration of flange as output signal |