modelAngularSpeedControlledMachine
Signal angular speed input machine
Extends from ElectroMechanicalDrives.Icons.Machine.
Information
This is an idealized angular speed controlled electric machine model. The actual angular speed of the electric machine can be adjusted by means of the signal input. Make sure that speed discontinuouties do not occur.
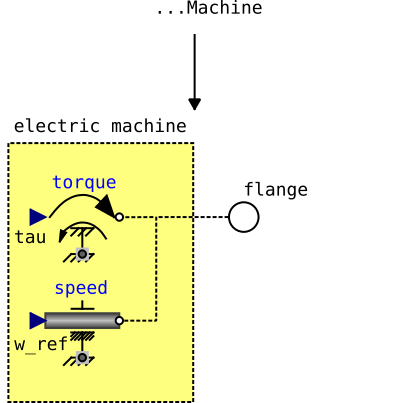
Fig. 1: Principle of controlled machine model without gear
The following variables are calculated in the model
- Machine
aMachine= angular acceleration of machinephiMachine= mechanical angle of machinewMachine= angular velocity of machinetauMachine= (electrical) torque of machinepowerMachine= power of machine
Notes
- Electrical connections are not modeled. The machine will always drive at the controlled input speed.
- In case of numerical issues, change parameter
exacttofalse
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | exact | true | true/false exact treatment/filtering the input signal |
| Modelica.Units.SI.Frequency | f_crit | 50 | if exact=false, critical frequency of filter to filter input signal |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | Shaft flange | |
| Modelica.Blocks.Interfaces.RealInput | w_ref | Reference angular speed as input signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Angle | phiMachine | Absolute rotation angle of machine | |
| Modelica.Units.SI.AngularVelocity | wMachine | speedMachineSensor.w | Angular velcocity of machine |
| Modelica.Units.SI.AngularAcceleration | aMachine | Absolute rotational acceleration of machine | |
| Modelica.Units.SI.Torque | tauMachine | torqueMachineSensor.tau | Torque of machine |
| Modelica.Units.SI.Power | powerMachine | powerMachineSensor.power | Power of machine |
| Modelica.Mechanics.Rotational.Sources.Speed | speed | ||
| Modelica.Mechanics.Rotational.Sensors.TorqueSensor | torqueMachineSensor | ||
| Modelica.Mechanics.Rotational.Sensors.PowerSensor | powerMachineSensor | ||
| Modelica.Mechanics.Rotational.Sensors.SpeedSensor | speedMachineSensor |