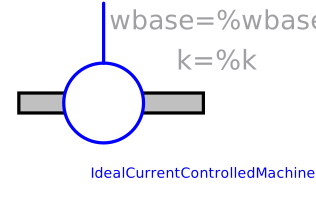
modelIdealCurrentControlledMachine
Ideal electric machine with current control input
Information
This model is a simplification over IdealCurrentFedMachine, where the electrical connections are replaced by a current input.
v = k*w
tau = -k*i
Where k = kBase in the base velocity range w ≤ wBase.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useSupport | false | = true, if support flange enabled, otherwise implicitly grounded |
| Modelica.Units.SI.ElectricalTorqueConstant | kBase | 1 | Transformation coefficient of base velocity range |
| Modelica.Units.SI.AngularVelocity | wBase | Maximum base angular velocity |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | i | Controlled current input | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | ||
| Modelica.Mechanics.Rotational.Interfaces.Support | support | Support/housing of emf shaft |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Voltage | v | Voltage drop between the two pins | |
| Modelica.Units.SI.Power | power | Power | |
| Modelica.Units.SI.Angle | phi | Angle of shaft flange with respect to support (= flange.phi - support.phi) | |
| Modelica.Units.SI.AngularVelocity | w | Angular velocity of flange relative to support | |
| Modelica.Units.SI.ElectricalTorqueConstant | k | Transformation coefficient of base speed range | |
| Modelica.Units.SI.Torque | tau | flange.tau | Torque acting at flange |
| Modelica.Units.SI.Torque | tauElectrical | -tau | Electrical torque |