modelTorqueControlledMachine
Signal torque input machine
Extends from ElectroMechanicalDrives.Icons.Machine.
Information
This is an idealized torque controlled electric machine model. The actual torque of the electric machine can be adjusted by means of the signal input.
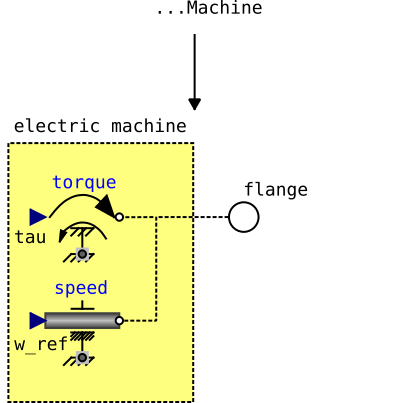
Fig. 1: Principle of controlled machine model without gear
The following variables are calculated in the model
- Machine
aMachine= angular acceleration of machinephiMachine= mechanical angle of machinewMachine= angular velocity of machinetauMachine= (electrical) torque of machinepowerMachine= power of machine
This machine model considers the following effect:
- Optional field weaking is considered by
-
- the maximum torque of the machine,
tauLimitforw ≤ wBase - the base speed limit
wBase - torque reduction proportial to
wBase/wforw > wBase
- the maximum torque of the machine,
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useFieldWeakening | false | True, if field weakening is considered |
| Modelica.Units.SI.Torque | tauLimit | Modelica.Constants.inf | Torque limit |
| Modelica.Units.SI.AngularVelocity | wBase | Modelica.Constants.inf | Base angular frequency |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | Shaft flange | |
| Modelica.Blocks.Interfaces.RealInput | tau_ref | Reference torque as input signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Sources.Torque | torque | ||
| TorqueLimiter | torqueLimiter | ||
| Modelica.Units.SI.AngularVelocity | wMachine | speedMachineSensor.w | Angular velcocity of machine |
| Modelica.Units.SI.Angle | phiMachine | Absolute rotation angle of machine | |
| Modelica.Units.SI.AngularAcceleration | aMachine | Absolute rotational acceleration of machine | |
| Modelica.Units.SI.Torque | tauMachine | torqueMachineSensor.tau | Torque of machine |
| Modelica.Units.SI.Power | powerMachine | powerMachineSensor.power | Power of machine |
| Modelica.Mechanics.Rotational.Sensors.SpeedSensor | speedMachineSensor | ||
| Modelica.Mechanics.Rotational.Sensors.TorqueSensor | torqueMachineSensor | ||
| Modelica.Mechanics.Rotational.Sensors.PowerSensor | powerMachineSensor |