modelClutch
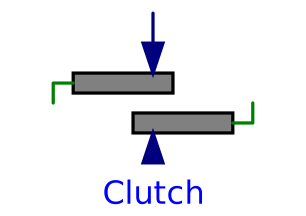
Clutch based on Coulomb friction
Extends from Modelica.Mechanics.Translational.Interfaces.PartialCompliantWithRelativeStates (Base model for the compliant connection of two translational 1-dim. shaft flanges where the relative position and relative velocities are used as states), Modelica.Mechanics.Translational.Interfaces.PartialFriction (Base model of Coulomb friction elements), Modelica.Thermal.HeatTransfer.Interfaces.PartialElementaryConditionalHeatPortWithoutT (Partial model to include a conditional HeatPort in order to dissipate losses, used for textual modeling, i.e., for elementary models).
Information
This translational clutch model is implemented based on the rotational clutch version.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real[:,2] | mu_pos | [0, 0.5] | [v,mu] positive sliding friction coefficient (v_rel>=0) |
| Real | peak | 1 | peak*mu_pos[1,2] = maximum value of mu for v_rel==0 |
| Real | cgeo | 1 | Geometry constant containing friction distribution assumption |
| Modelica.Units.SI.Force | fn_max | Maximum normal force | |
| Integer | Unknown (from PartialFriction) | 3 | Value of mode is not known |
| Integer | Free (from PartialFriction) | 2 | Element is not active |
| Integer | Forward (from PartialFriction) | 1 | v_relfric > 0 (forward sliding) |
| Integer | Stuck (from PartialFriction) | 0 | v_relfric = 0 (forward sliding, locked or backward sliding) |
| Integer | Backward (from PartialFriction) | -1 | v_relfric < 0 (backward sliding) |
| Boolean | useHeatPort (from PartialElementaryConditionalHeatPortWithoutT) | false | = true, if heatPort is enabled |
| Advanced | |||
| StateSelect | stateSelect (from PartialCompliantWithRelativeStates) | StateSelect.prefer | Priority to use s_rel and v_rel as states |
| SI.Distance | s_nominal (from PartialCompliantWithRelativeStates) | 1e-4 | Nominal value of s_rel (used for scaling) |
| SI.Velocity | v_small (from PartialFriction) | 1e-3 | Relative velocity near to zero (see model info text) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Flange_a | flange_a (from PartialTwoFlanges) | (left) driving flange (flange axis directed into cut plane, e. g. from left to right) | |
| Flange_b | flange_b (from PartialTwoFlanges) | (right) driven flange (flange axis directed out of cut plane) | |
| HeatTransfer.Interfaces.HeatPort_a | heatPort (from PartialElementaryConditionalHeatPortWithoutT) | Optional port to which dissipated losses are transported in form of heat | |
| Modelica.Blocks.Interfaces.RealInput | f_normalized | Normalized force signal 0..1 (normal force = fn_max*f_normalized; clutch is engaged if > 0) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | s_rel (from PartialCompliantWithRelativeStates) | Relative distance (= flange_b.s - flange_a.s) | |
| SI.Velocity | v_rel (from PartialCompliantWithRelativeStates) | Relative velocity (= der(s_rel)) | |
| SI.Force | f (from PartialCompliantWithRelativeStates) | Forces between flanges (= flange_b.f) | |
| SI.Velocity | v_relfric (from PartialFriction) | Relative velocity between frictional surfaces | |
| SI.Acceleration | a_relfric (from PartialFriction) | Relative acceleration between frictional surfaces | |
| SI.Force | f0 (from PartialFriction) | Friction force for v_relfric=0 and forward sliding | |
| SI.Force | f0_max (from PartialFriction) | Maximum friction force for v_relfric=0 and locked | |
| Boolean | free (from PartialFriction) | = true, if frictional element is not active | |
| Real | sa (from PartialFriction) | Path parameter of friction characteristic f = f(a_relfric) | |
| Boolean | startForward (from PartialFriction) | = true, if v_relfric=0 and start of forward sliding | |
| Boolean | startBackward (from PartialFriction) | = true, if v_relfric=0 and start of backward sliding | |
| Boolean | locked (from PartialFriction) | = true, if v_relfric=0 and not sliding | |
| Integer | mode (from PartialFriction) | Mode of friction (-1: backward sliding, 0: stuck, 1: forward sliding, 2: inactive, 3: unknown) | |
| SI.Power | lossPower (from PartialElementaryConditionalHeatPortWithoutT) | Loss power leaving component via heatPort (> 0, if heat is flowing out of component) | |
| Real | mu0 | Friction coefficient for v=0 and forward sliding | |
| Modelica.Units.SI.Force | fn | Normal force (fn=fn_max*f_normalized) | |
| Modelica.Units.SI.Acceleration | a_rel | Relative angular acceleration (= der(v_rel)) |