modelPMSM
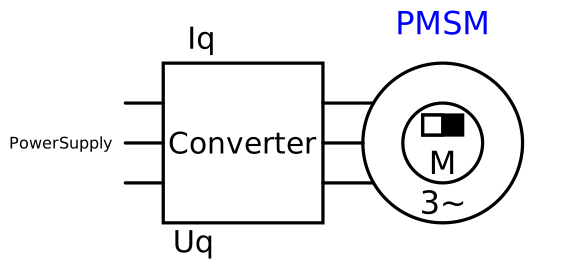
Model of a synchronous servo motor that can be parametrized with typical supplier data such as from Siemens 1FT6. Field weakening current is set to zero.
Parameters
| Type | Name | Default | Description |
|---|
| Engineering data |
| SI.Conversions.NonSIunits.AngularVelocity_rpm | n_n | | Rated speed |
| Integer | n_polePairs | | Number of pole pairs |
| SI.Torque | M_n | | Rated torque (100 K) |
| SI.Current | I_n | | Rated current (100 K) |
| SI.Torque | M_0_100 | | Stall torque (100 K) |
| SI.Current | I_0_100 | | Stall current (100 K) |
| SI.Torque | M_0_60 | | Stall torque (60 K) |
| SI.Current | I_0_60 | | Stall current (60 K) |
| SI.Inertia | J | | Motor inertia |
| Limiting data |
| SI.Conversions.NonSIunits.AngularVelocity_rpm | n_max | | Max. permissible speed (mech.) |
| SI.Torque | M_max | | Maximum torque |
| SI.Current | I_max | | Maximum current |
| SI.Temperature | T_max | 413.15 | Permissible temperature |
| SI.Voltage | U_eff_max | 380 | Voltage limit of motor module |
| Physical constants |
| SI.ElectricalTorqueConstant | k_T_0_100 | M_0_100/I_0_100 | Rated torque constant |
| SI.Resistance | R_ph_20 | | Winding resistance at 20degC |
| SI.Inductance | L_D | | Rotating field inductance |
| SI.Time | T_th | | Thermal time constant |
| Real | C_F | (T_ref_100/R_heat - Q_R_N)/SI.Conversions.from_rpm(n_n)^1.5 | Constant relating friction torque and square root of angular velocity |
| Start conditions |
| SI.Temperature | T_start | | Start temperature |
| Safety factors |
| Real | S_n | 1 | Safety factor (>=1) for rotation speed (S_n * n <= n_max) |
| Real | S_M | 1 | Safety factor (>=1) for torque (S_n * M <= M_max) |
| Real | S_U | 1 | Safety factor (>=1) for voltage (S_n * u <= u_max) |
| Real | S_T | 1 | Safety factor (>=1) for temperature (S_n * T <= T_max) |