modelQuad
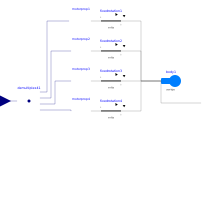
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Mass | mass | 1 | mass |
| SI.Time | time_constant | 0.1 | motor time constant |
| SI.Force | thrust_max | 10 | motor maximum thrust |
| Real | thrust_to_torque | 0.1 | thrust to torque gain |
| SI.Length[4] | arm_lengths | {0.2, 0.2, 0.2, 0.2} | length of arms |
| NonSI.Angle_deg[4] | arm_angles | {0, 90, 180, 270} | rotation of arms |
| SI.Inertia | J_x | 1 | |
| SI.Inertia | J_y | 1 | |
| SI.Inertia | J_z | 1 | |
| SI.Inertia | J_xz | 0 | inertia terms |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedrotation1 | ||
| Flight.Parts.MotorProp | motorprop1 | ||
| Flight.Parts.MotorProp | motorprop2 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedrotation2 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedrotation3 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedrotation4 | ||
| Flight.Parts.MotorProp | motorprop4 | ||
| Modelica.Blocks.Routing.DeMultiplex4 | demultiplex41 | ||
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_b | ||
| Flight.Parts.MotorProp | motorprop3 | ||
| Modelica.Mechanics.MultiBody.Parts.Body | body1 | ||
| Modelica.Blocks.Interfaces.RealInput[4] | u |