modelPIDInitialDerivativeOutput
Test model for LimPID controller with initial output of the derivative term specified
Information
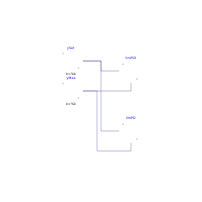
Validation test for the block IDEAS.Controls.OBC.CDL.Reals.PID.
This model validates setting the initial output of the controller to a specified value. Note that the control error must be zero for the initial output to be at the specified value. See the description of IDEAS.Controls.OBC.CDL.Reals.PID.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| IDEAS.Controls.OBC.CDL.Reals.Sources.Constant | ySet | Set point | |
| IDEAS.Controls.OBC.CDL.Reals.Sources.Constant | yMea | Measured value | |
| IDEAS.Controls.OBC.CDL.Reals.PID | limPID | PID controller | |
| IDEAS.Controls.OBC.CDL.Reals.PID | limPD | PD controller |
Revisions
-
April 8, 2020, by Michael Wetter:
First implementation.