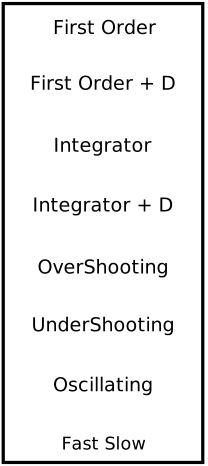
modelTypicalTF
This model contains a set of typical process transfer functions
Information
Description
This model is a container of different trasfer functions that can model the typical processes.
The parameters of each TF (listed in a table below), can be modified in order to adapt each process to the user's needs.
| Integrator | |
|---|---|
Y(s) 1 ---- = ----- U(s) 5s |
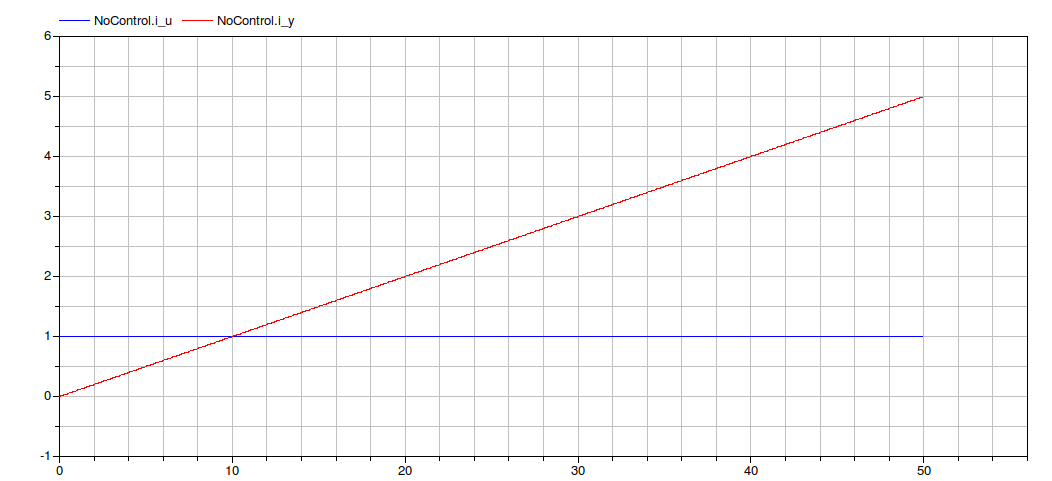
| Integrator + delay | |
|---|---|
Y(s) 1 -2s ---- = ----- e U(s) 5s |
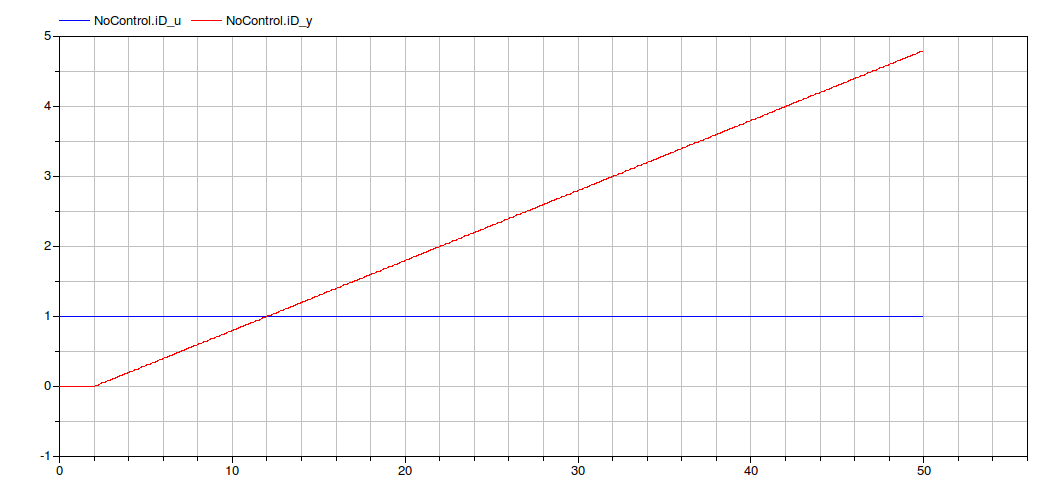
| First Order | |
|---|---|
Y(s) 1 ---- = -------- U(s) 1 + 5s |
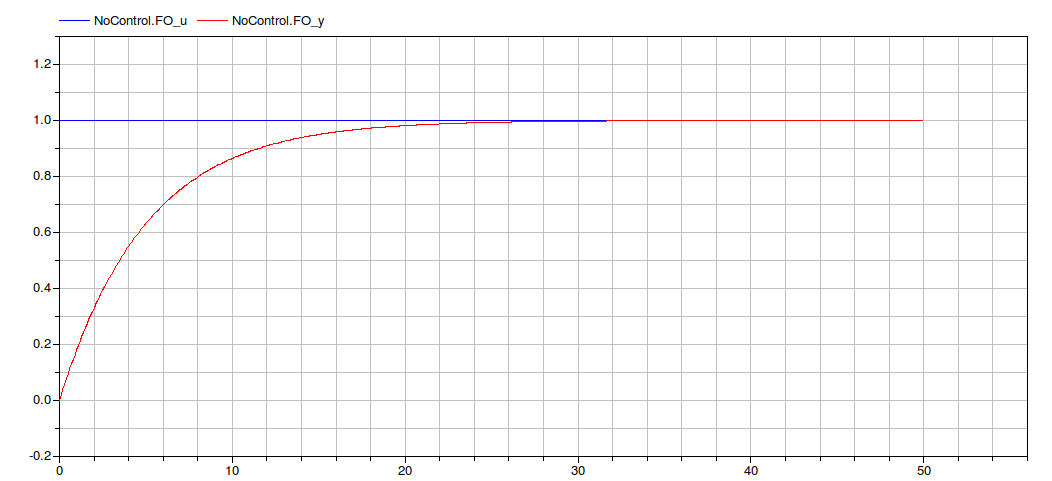
| First Order + delay | |
|---|---|
Y(s) 1 -2s ---- = -------- e U(s) 1 + 5s |
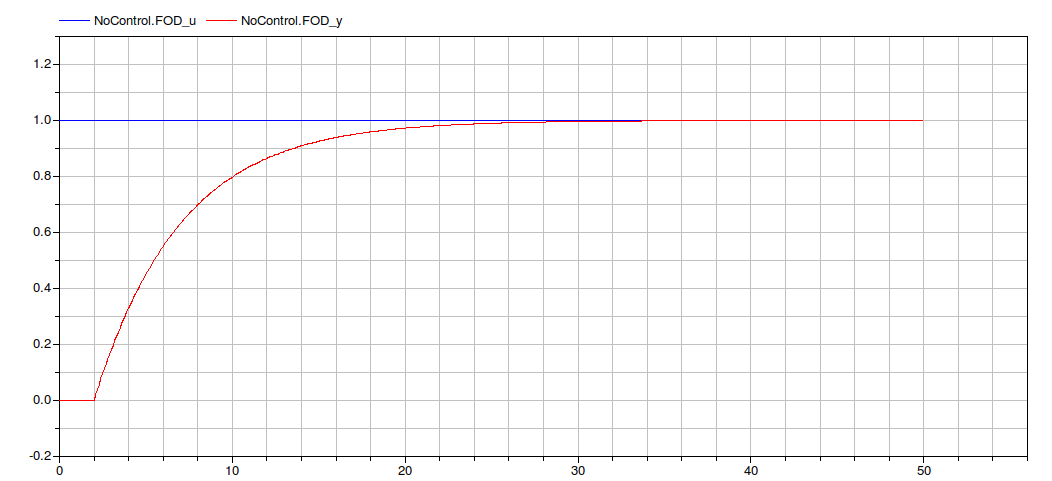
| Fast Slow | |
|---|---|
Y(s) 1 + 5.8s ---- = -------------- U(s) (1 + 6s)(1+s) |
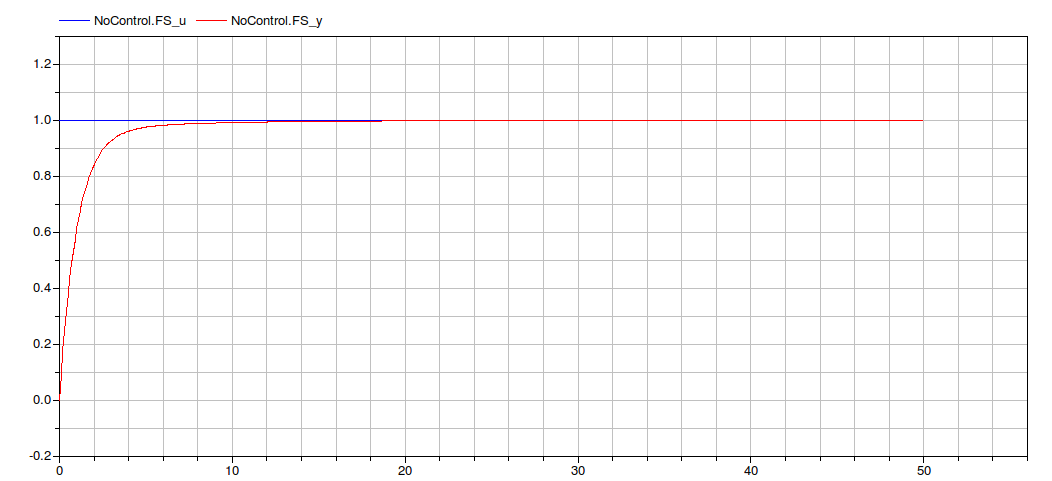
| Overshooting | |
|---|---|
Y(s) 1 + 8s ---- = --------------- U(s) (1 + 5s)(1+2s) |
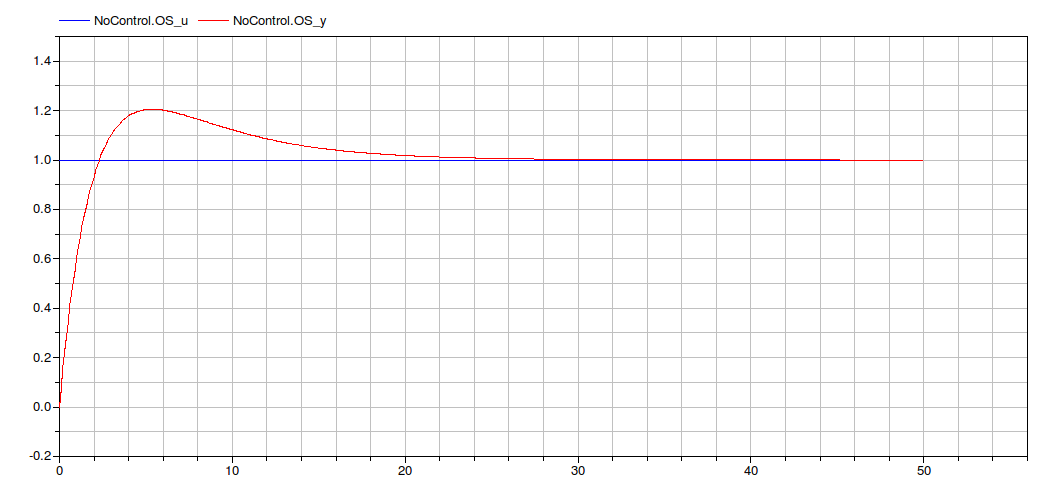
| Undershooting | |
|---|---|
Y(s) 1 - 5.5s ---- = --------------- U(s) (1 + 5s)(1+2s) |
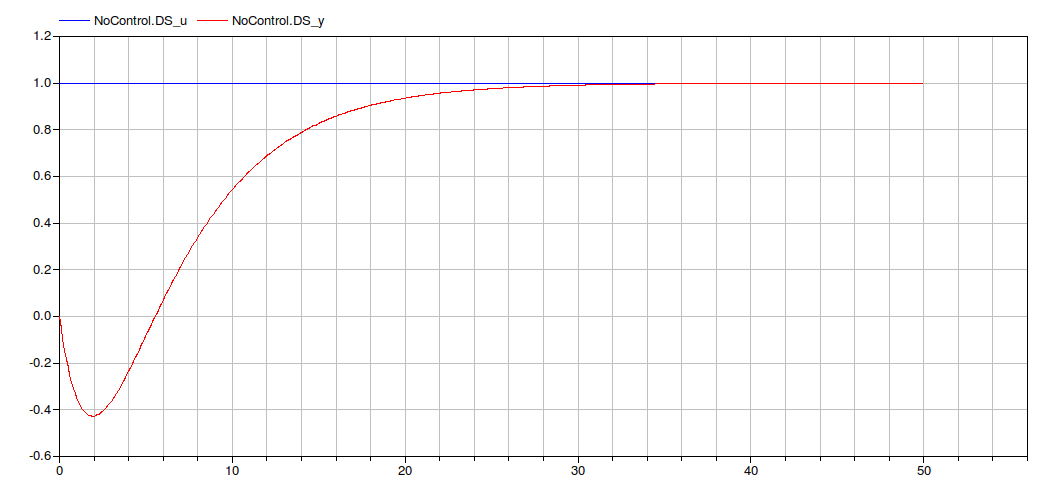
| Complex Poles | |
|---|---|
Y(s) 1 ---- = -------------------- U(s) 1 + 1.2 s + 0.025s |
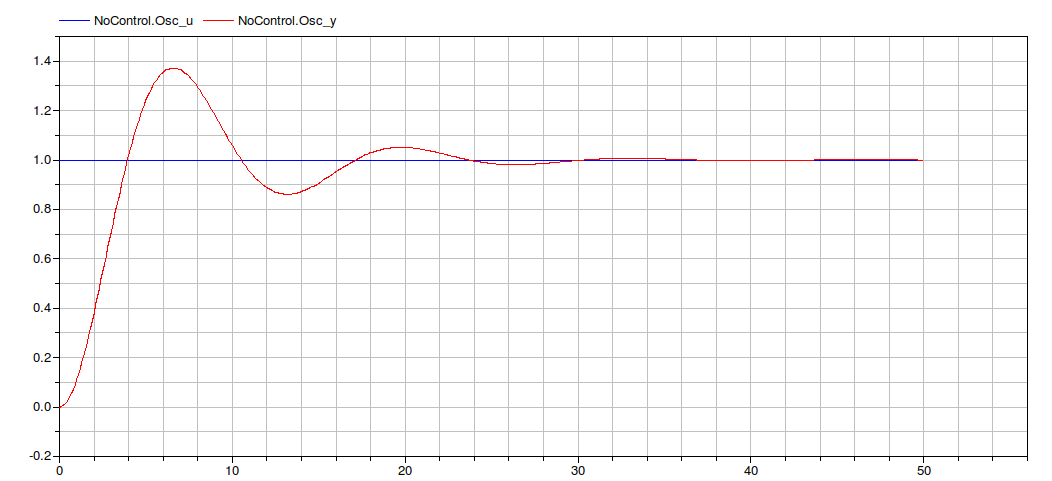
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| First Order | |||
| Real | mu_FO | 1 | Gain |
| Real | T_FO | 5 | Time constant |
| First Order + Delay | |||
| Real | mu_FOD | 1 | Gain |
| Real | T_FOD | 5 | Time constant |
| Real | delay_FOD | 2 | Time delay |
| Integrator | |||
| Real | mu_i | 0.1 | Gain |
| Integrator + Delay | |||
| Real | mu_iD | 0.1 | Gain |
| Real | delay_iD | 2 | Time delay |
| OverShooting system | |||
| Real | mu_OS | 1 | Gain |
| Real | Tau_OS | 8 | Zero's time constant |
| Real | T1_OS | 5 | Dominant pole time constant |
| Real | T2_OS | 2 | Second pole time constant |
| UnderShooting system | |||
| Real | mu_US | 1 | Gain |
| Real | Tau_US | -5.5 | Zero's time constant |
| Real | T1_US | 5 | Dominant pole time constant |
| Real | T2_US | 2 | Second pole time constant |
| Complex poles | |||
| Real | mu | 1 | Gain |
| Real | xi | 0.3 | Damping coefficient |
| Real | omega | 0.5 | Natural frequency |
| Fast-Slow system | |||
| Real | mu_FS | 1 | Gain |
| Real | Tau_FS | 5.8 | Zero's time constant |
| Real | T1_FS | 6 | Dominant pole time constant |
| Real | T2_FS | 1 | Second pole time constant |
Connectors
Components
| Type | Name | Default | Description |
|---|---|---|---|
| LinearSystems.Continuous.FirstOrder | firstOrder | ||
| LinearSystems.Continuous.FirstOrder | firstOrder1 | ||
| IndustrialControlSystems.LinearSystems.Continuous.Delay | delay | ||
| LinearSystems.Continuous.Integrator | integrator | ||
| LinearSystems.Continuous.Integrator | integrator1 | ||
| IndustrialControlSystems.LinearSystems.Continuous.Delay | delay1 | ||
| LinearSystems.Continuous.LeadLag | leadLag | ||
| LinearSystems.Continuous.FirstOrder | firstOrder2 | ||
| LinearSystems.Continuous.LeadLag | leadLag1 | ||
| LinearSystems.Continuous.FirstOrder | firstOrder3 | ||
| LinearSystems.Continuous.ComplexPoles | complexPoles | ||
| LinearSystems.Continuous.LeadLag | leadLag2 | ||
| LinearSystems.Continuous.FirstOrder | firstOrder4 |
Revisions
- Industrial Control Systems (v 1.0.0) : April-May 2012
- List of revisions:
- 11 May 2012 (author: Marco Bonvini)
- Main Authors:
- Marco Bonvini; <bonvini@elet.polimi.it>
- Alberto Leva <leva@elet.polimi.it>
- Politecnico di Milano
- Dipartimento di Elettronica e Informazione
- Via Ponzio 34/5
- 20133 Milano - ITALIA -
- Copyright:
- Copyright © 2010-2012, Marco Bonvini and Alberto Leva.
- The IndustrialControlSystems package is free software; it can be redistributed and/or modified under the terms of the Modelica license.