modelMotorWithCurrentControl
Synchronous machine with current controller and measurement noise
Extends from Modelica.Electrical.Machines.Icons.TransientMachine.
Information
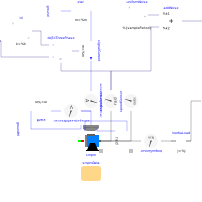
A synchronous machine with permanent magnets, current controller and measurement noise of ±0.01 rad accelerates a quadratic speed dependent load from standstill. The rms values of d- and q-current in rotor fixed coordinate system are converted to three-phase currents, and fed to the machine. The result shows that the torque is influenced by the q-current, whereas the stator voltage is influenced by the d-current.
Default machine parameters of model SM_PermanentMagnet are used.
This motor is used in the Examples.Noise.ActuatorWithNoise actuator example
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | m | 3 | Number of phases |
| SI.Voltage | VNominal | 100 | Nominal RMS voltage per phase |
| SI.Frequency | fNominal | 50 | Nominal frequency |
| SI.Frequency | f | 50 | Actual frequency |
| SI.Time | tRamp | 1 | Frequency ramp |
| SI.Torque | TLoad | 181.4 | Nominal load torque |
| SI.Time | tStep | 1.2 | Time of load torque step |
| SI.Inertia | JLoad | 0.29 | Load's moment of inertia |
| Modelica.Electrical.Machines.Utilities.ParameterRecords.SM_PermanentMagnetData | smpmData | Data for motor |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | iq_rms1 | ||
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange | Right flange of shaft | |
| Modelica.Blocks.Interfaces.RealOutput | phi | Absolute angle of flange as output signal |
Components
Revisions
| Date | Description | ||
|---|---|---|---|
| June 22, 2015 |
|
