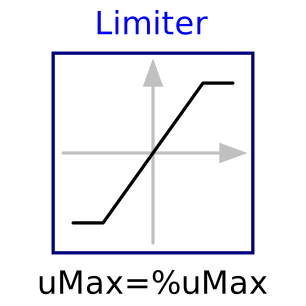
blockLimiter
Limit the range of a signal
Extends from Interfaces.SISO (Single Input Single Output continuous control block).
Information
The Limiter block passes its input signal as output signal as long as the input is within the specified upper and lower limits. If this is not the case, the corresponding limits are passed as output.
The parameter homotopyType in the Advanced tab specifies the
simplified behaviour if homotopy-based initialization is used:
NoHomotopy: the actual expression with limits is usedLinear: a linear behaviour y = u is assumed (default option)UpperLimit: it is assumed that the output is stuck at the upper limit u = uMaxLowerLimit: it is assumed that the output is stuck at the lower limit u = uMin
If it is known a priori in which region the input signal will be located, this option can help a lot by removing one strong nonlinearity from the initialization problem.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | uMax | Upper limits of input signals | |
| Real | uMin | -uMax | Lower limits of input signals |
| Advanced | |||
| Boolean | strict | false | = true, if strict limits with noEvent(..) |
| Initialization | |||
| Types.LimiterHomotopy | homotopyType | Modelica.Blocks.Types.LimiterHomotopy.Linear | Simplified model for homotopy-based initialization |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |