
modelIMC_DCBraking
Induction machine with DC current braking
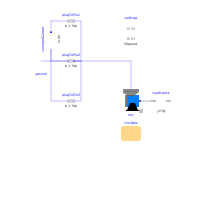
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
The stator windings of an induction machine are fed by a DC current, causing a stationary current space phasor. Since the rotor is turning, voltage is induced in the rotor cage which in turn drives rotor currents. This creates a braking torque.
Choose a layout and plot tauElectrical and tauShaft versus wMechanical.
Default machine parameters are used.
References
| [Fischer2017] | R. Fischer, Elektrische Maschinen, 17th ed., chapter 5.3.3., Hanser, ISBN 978-3-446-45218-3, 2017. |
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | m | 3 | Number of phases |
| SI.AngularVelocity | w0 | 2*pi*imcData.fsNominal/imcData.p | Initial mechanical speed |
| SI.Inertia | JLoad | 4*imcData.Jr | Load's moment of inertia |
| Modelica.Electrical.Machines.Utilities.DcBrakeSettings | settings | ||
| Modelica.Electrical.Machines.Utilities.ParameterRecords.IM_SquirrelCageData | imcData |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Torque | tauElectrical | imc.tauElectrical | Electrical torque |
| SI.Torque | tauShaft | imc.tauShaft | Shaft torque |
| SI.AngularVelocity | wMechanical | imc.wMechanical | Shaft speed |
| Modelica.Electrical.Machines.BasicMachines.InductionMachines.IM_SquirrelCage | imc | ||
| Modelica.Mechanics.Rotational.Components.Inertia | loadInertia | ||
| Modelica.Electrical.Machines.Utilities.TerminalBox | terminalBox | ||
| Modelica.Electrical.Polyphase.Basic.PlugToPin_p | plugToPin1 | ||
| Modelica.Electrical.Polyphase.Basic.PlugToPin_p | plugToPin2 | ||
| Modelica.Electrical.Polyphase.Basic.PlugToPin_p | plugToPin3 | ||
| Modelica.Electrical.Analog.Sources.ConstantCurrent | constantCurrent | ||
| Modelica.Electrical.Analog.Basic.Ground | ground |