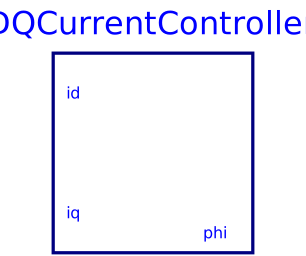
modelDQCurrentController
Extends from Modelica.Blocks.Interfaces.MO (Multiple Output continuous control block).
Information
Simple Current controller
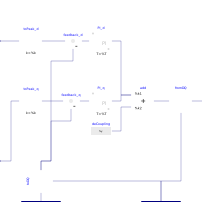
The desired d- and q-component of the space phasor current in rotor fixed coordinate system are given by inputs id and iq.
Using the given rotor position (input phi), the actual three-phase currents are measured and transformed to the d-q coordinate system.
Two PI controllers determine the necessary d- and q- voltages, which are transformed back to three-phase (output y[3]).
They can be used to feed a voltage source which in turn feeds a permanent magnet synchronous machine.
Inputs d and q can be given either as peak values (useRMS=false) or as RMS (useRMS=true).
The correction by factor √2 is done automatically.
The measured currents iActual[m] are assumed to be instantaneous values.
Note: No care is taken for current or voltage limiting, as well as for field weakening.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | m | 3 | Number of phases |
| Integer | p | Number of pole pairs | |
| Boolean | useRMS | true | If true, inputs dq are multiplied by sqrt(2) |
| SI.Frequency | fsNominal | Nominal frequency | |
| SI.Voltage | VsOpenCircuit | Open circuit RMS voltage per phase @ fsNominal | |
| SI.Resistance | Rs | Stator resistance per phase | |
| SI.Inductance | Ld | Inductance in d-axis | |
| SI.Inductance | Lq | Inductance in q-axis | |
| Boolean | decoupling | false | Use decoupling network |
| SI.MagneticFlux | psiM | sqrt(2)*VsOpenCircuit/(2*pi*fsNominal) | Approximation of magnetic flux linkage |
| Integer | nout (from MO) | 1 | Number of outputs |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealOutput[nout] | y (from MO) | Connector of Real output signals | |
| Modelica.Blocks.Interfaces.RealInput | id | Reference of d-current | |
| Modelica.Blocks.Interfaces.RealInput | iq | Reference of q-current | |
| Modelica.Blocks.Interfaces.RealInput | phi | Rotor angle | |
| Modelica.Blocks.Interfaces.RealInput[m] | iActual | Measured three-phase currents |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.AngularVelocity | omega | p*der(phi) | |
| SI.Voltage | Vd | sqrt(2)*(Rs*id - omega*Lq*iq) | |
| SI.Voltage | Vq | sqrt(2)*(Rs*iq + omega*Ld*id) + omega*psiM | |
| Machines.Utilities.FromDQ | fromDQ | ||
| Machines.Utilities.ToDQ | toDQ | ||
| Modelica.Blocks.Math.Gain | toPeak_d | ||
| Modelica.Blocks.Math.Gain | toPeak_q | ||
| Modelica.Blocks.Math.Feedback | feedback_d | ||
| Modelica.Blocks.Math.Feedback | feedback_q | ||
| Modelica.Blocks.Continuous.PI | PI_d | ||
| Modelica.Blocks.Continuous.PI | PI_q | ||
| Modelica.Blocks.Math.Add[2] | add | ||
| Modelica.Blocks.Sources.RealExpression[2] | deCoupling |