modelController
P-PI cascade controller for one axis
Extends from Blocks.Icons.Block (Basic graphical layout of input/output block).
Information
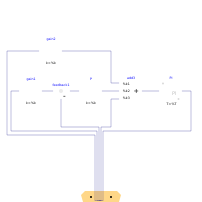
This controller has an inner PI controller to control the motor speed, and an outer P controller to control the motor position of one axis. The reference signals are with respect to the gear-output, and the gear ratio is used in the controller to determine the motor reference signals. All signals are communicated via the "axisControlBus".
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | kp | 10 | Gain of position controller |
| Real | ks | 1 | Gain of speed controller |
| SI.Time | Ts | 0.01 | Time constant of integrator of speed controller |
| Real | ratio | 1 | Gear ratio of gearbox |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Examples.Systems.RobotR3.Utilities.AxisControlBus | axisControlBus |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Math.Gain | gain1 | ||
| Modelica.Blocks.Continuous.PI | PI | ||
| Modelica.Blocks.Math.Feedback | feedback1 | ||
| Modelica.Blocks.Math.Gain | P | ||
| Modelica.Blocks.Math.Add3 | add3 | ||
| Modelica.Blocks.Math.Gain | gain2 |