modelMotor
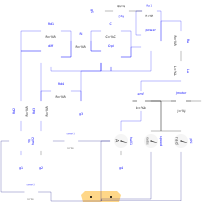
Motor model including current controller of r3 motors
Extends from Electrical.Machines.Icons.Machine (Generic icon of an electric machine).
Information
Default values are given for the motor of joint 1. The input of the motor is the desired current (the actual current is proportional to the torque produced by the motor).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Inertia | J | 0.0013 | Moment of inertia of motor |
| Real | k | 1.1616 | Gain of motor |
| Real | w | 4590 | Time constant of motor |
| Real | D | 0.6 | Damping constant of motor |
| SI.AngularVelocity | w_max | 315 | Maximum speed of motor |
| SI.Current | i_max | 9 | Maximum current of motor |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange_motor | ||
| Modelica.Mechanics.MultiBody.Examples.Systems.RobotR3.Utilities.AxisControlBus | axisControlBus |