modelPipeWithScalarField
Visualizing a pipe with a scalar field
Information
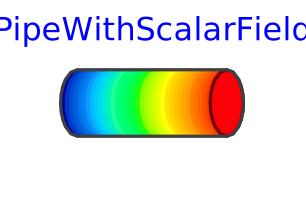
Model PipeWithScalarField visualizes a pipe and a scalar
field along the pipe axis. The latter is shown by mapping scalar
field to color values with a color map and utilizing this color
at the perimeter associated with the corresponding axis location.
Typically the scalar field value is a temperature, but might
be also another quantity.
Predefined color maps are available from
MultiBody.Visualizers.Colors.ColorMaps
and can be selected via parameter "colorMap".
A color map with the corresponding scalar field values can be exported
as vector-graphics in svg-format with function
MultiBody.Visualizers.Colors.colorMapToSvg.
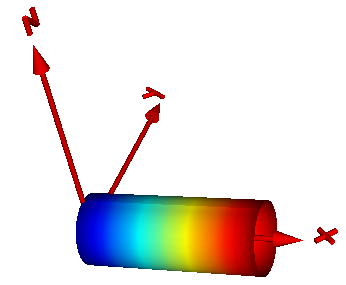
The position and orientation of the center of the
circle at the left end of the pipe is defined via parameters
"r_0" and "R", respectively. The pipe axis is oriented along
the x-axis of the local coordinate system described by "R",
see figure below:
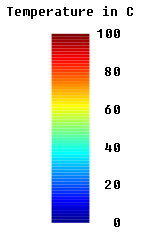
The color coding is shown in the next figure. It was generated with
MultiBody.Visualizers.Colors.colorMapToSvg
using the following call:
colorMapToSvg(Modelica.Mechanics.MultiBody.Visualizers.Colors.ColorMaps.jet(),
              height=50, nScalars=6, T_max=100, caption="Temperature in C");
Parameters
| Type | Name | Default | Description |
|---|
| Surface properties |
| SI.Radius | rOuter | | Outer radius of pipe |
| SI.Length | length | | Length of pipe |
| Integer | n_rOuter | 30 | Number of points along outer radius |
| Integer | n_length | 10 | Number of points along length |
| Types.SpecularCoefficient | specularCoefficient | 0.7 | Reflection of ambient light (= 0: light is completely absorbed) |
| Real | transparency | 0 | Transparency of shape: 0 (= opaque) ... 1 (= fully transparent) |
| Color coding |
| Real[:] | xsi | Modelica.Math.Vectors.relNodePositions(12) | Vector of relative positions along the pipe with x[1] = 0, x[end] = 1 |
| Real | T_min | | Minimum value of T that corresponds to colorMap[1,:] |
| Real | T_max | | Maximum value of T that corresponds to colorMap[end,:] |
| Integer | n_colors | 64 | Number of colors in the colorMap |
Components
| Type | Name | Default | Description |
|---|
| Frames.Orientation | R | Frames.nullRotation() | Orientation object to rotate the world frame into the surface frame |
| SI.Position[3] | r_0 | {0, 0, 0} | Position vector from origin of world frame to origin of surface frame, resolved in world frame |
| Real[size(xsi, 1)] | T | | Vector of values at positions xsi*length (will be visualized by color) |
Contents
| Name | Description |
|---|
 colorMap | |