modelIdealRollingWheel
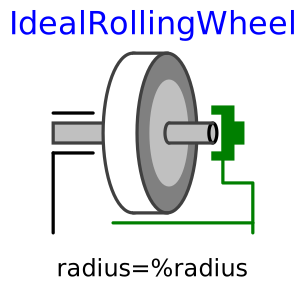
Simple 1-dim. model of an ideal rolling wheel without inertia
Extends from Rotational.Interfaces.PartialElementaryRotationalToTranslational (Partial model to transform rotational into translational motion).
Information
A simple kinematic model of a rolling wheel which has no inertia and no rolling resistance. This component defines the kinematic constraint:
(flangeR.phi - internalSupportR.phi) * radius = (flangeT.s - internalSupportT.s);
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | useSupportR (from PartialElementaryRotationalToTranslational) | false | = true, if rotational support flange enabled, otherwise implicitly grounded |
| Boolean | useSupportT (from PartialElementaryRotationalToTranslational) | false | = true, if translational support flange enabled, otherwise implicitly grounded |
| SI.Distance | radius | Wheel radius |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Rotational.Interfaces.Flange_a | flangeR (from PartialElementaryRotationalToTranslational) | Flange of rotational shaft | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | flangeT (from PartialElementaryRotationalToTranslational) | Flange of translational rod | |
| Rotational.Interfaces.Support | supportR (from PartialElementaryRotationalToTranslational) | Rotational support/housing of component | |
| Translational.Interfaces.Support | supportT (from PartialElementaryRotationalToTranslational) | Translational support/housing of component |