modelRelativeStates
Definition of relative state variables
Extends from Translational.Interfaces.PartialTwoFlanges (Component with two translational 1D flanges).
Information
Usually, the absolute position and the absolute velocity of Modelica.Mechanics.Translational.Inertia models are used as state variables. In some circumstances, relative quantities are better suited, e.g., because it may be easier to supply initial values. In such cases, model RelativeStates allows the definition of state variables in the following way:
- Connect an instance of this model between two flange connectors.
- The relative position and the relative velocity between the two connectors are used as state variables.
An example is given in the next figure
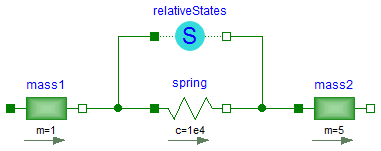
Here, the relative position and the relative velocity between the two masses are used as state variables. Additionally, the simulator selects either the absolute position and absolute velocity of model mass1 or of model mass2 as state variables.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| StateSelect | stateSelect | StateSelect.prefer | Priority to use the relative angle and relative speed as states |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Flange_a | flange_a (from PartialTwoFlanges) | (left) driving flange (flange axis directed into cut plane, e. g. from left to right) | |
| Flange_b | flange_b (from PartialTwoFlanges) | (right) driven flange (flange axis directed out of cut plane) |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Position | s_rel | Relative position used as state variable | |
| SI.Velocity | v_rel | Relative velocity used as state variable | |
| SI.Acceleration | a_rel | Relative angular acceleration |