
modelDCPM_CurrentControlled
Current controlled DCPM drive
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
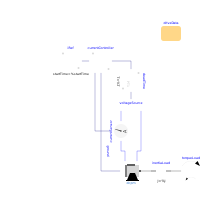
Simulates a current controlled DCPM machine. The load applies a linearly speed dependent torque, which in the end causes the drive to operate in nominal operation.
Additionally, the handling of parameter records can be tested: By simply redeclaring the machine parameter record instantiated in the drive parameter record, a machine with different parameters can be simulated.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| ModelicaTest.Electrical.Machines.DCPM_Utilities.DriveData | driveData |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| ModelicaTest.Electrical.Machines.DCPM_Utilities.DCPM | dcpm | ||
| Modelica.Electrical.Analog.Basic.Ground | ground | ||
| Modelica.Blocks.Sources.Step | iRef | ||
| Modelica.Mechanics.Rotational.Components.Inertia | inertiaLoad | ||
| Modelica.Mechanics.Rotational.Sources.LinearSpeedDependentTorque | torqueLoad | ||
| Modelica.Electrical.Analog.Sources.SignalVoltage | voltageSource | ||
| Modelica.Electrical.Analog.Sensors.CurrentSensor | currentSensor | ||
| Modelica.Blocks.Continuous.FirstOrder | deadTime | ||
| Modelica.Electrical.Machines.Examples.ControlledDCDrives.Utilities.LimitedPI | currentController |