modelPrismaticWithLengthConstraint
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialTwoFrames (Base model for components providing two frame connectors + outer world + assert to guarantee that the component is connected), ObsoleteModelica3.Icons.ObsoleteModel (Icon for an obsolete model (use only for this case)).
Information
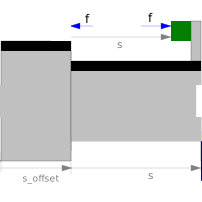
Joint where frame_b is translated along axis n which is fixed in frame_a. The two frames coincide when "s + s_offset = 0", where "s_offset" is a parameter with a zero default and "s" is the relative distance.
This variant of the prismatic joint is designed to work together with a length constraint in a kinematic loop. This means that the relative distance "s" of the joint is computed such that the length constraint is fulfilled.
Usually, this joint should not be used by a user of the MultiBody library. It is only provided to built-up the Modelica.Mechanics.MultiBody.Joints.Assemblies.JointXYZ joints.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if animation shall be enabled |
| SI.Position | length | 1 | Fixed length of length constraint |
| Modelica.Mechanics.MultiBody.Types.Axis | n | {1, 0, 0} | Axis of translation resolved in frame_a (= same as in frame_b) |
| SI.Position | s_offset | 0 | Relative distance offset (distance between frame_a and frame_b = s(t) + s_offset) |
| SI.Position | s_guess | 0 | Select the configuration such that at initial time |s(t0)-s_guess|is minimal |
| Boolean | positiveBranch | Selection of one of the two solutions of the non-linear constraint equation | |
| Real[3] | e | Modelica.Math.Vectors.normalize(n) | Unit vector in direction of translation axis, resolved in frame_a |
| Animation › if animation = true | |||
| Modelica.Mechanics.MultiBody.Types.Axis | boxWidthDirection | {0, 1, 0} | Vector in width direction of box, resolved in frame_a |
| SI.Distance | boxWidth | world.defaultJointWidth | Width of prismatic joint box |
| SI.Distance | boxHeight | boxWidth | Height of prismatic joint box |
| Advanced | |||
| Boolean | axisForceBalance | true | = true, if force balance of flange axis with the frame_b connector (axis.f = -e*frame_b.f) shall be defined. Otherwise this equation has to be provided outside of this joint |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | axis | 1-dim. translational flange that drives the joint | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | bearing | 1-dim. translational flange of the drive bearing | |
| Modelica.Blocks.Interfaces.RealInput[3] | position_a | Position vector from frame_a to frame_a side of length constraint, resolved in frame_a of revolute joint | |
| Modelica.Blocks.Interfaces.RealInput[3] | position_b | Position vector from frame_b to frame_b side of length constraint, resolved in frame_b of revolute joint |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.Color | boxColor | Modelica.Mechanics.MultiBody.Types.Defaults.JointColor | Color of prismatic joint box |
| Modelica.Mechanics.MultiBody.Types.SpecularCoefficient | specularCoefficient | world.defaultSpecularCoefficient | Reflection of ambient light (= 0: light is completely absorbed) |
| SI.Position | s | Relative distance between frame_a and frame_b along axis n = s + s_offset) | |
| SI.Position | distance | Relative distance between frame_a and frame_b along axis n | |
| SI.Position[3] | r_rel_a | Position vector from frame_a to frame_b resolved in frame_a | |
| SI.Force | f | = axis.f (driving force in the axis) |
Contents
| Name | Description |
|---|---|
| selectBranchprotected | Determine branch which is closest to initial angle=0 |