modelSensorlessBLDC
Application of sensorless BLDC commutation
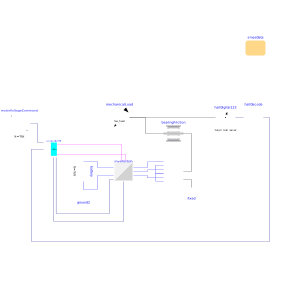
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
This model demonstrates how to do the placement of the hall sensors with the induced phase current.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | m | 3 | Number of phases |
| Integer | PPZ | 6 | Motor pairs of poles |
| Modelica.Electrical.Machines.Utilities.SynchronousMachineData | smeeData |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Sensors.HallDigitalN | hallDigital123 | ||
| Modelica.Mechanics.Rotational.Sources.ConstantSpeed | mechanicalLoad | Replaceable mechanical attachment | |
| Modelica.Mechanics.Rotational.Components.Fixed | fixed | ||
| Blocks.HallDecode | hallDecode | ||
| Machines.PMSMm | pMSM_run | ||
| Converters.SwitchingIdeal.Inverter3ph | inverter3ph | ||
| Modelica.Electrical.Analog.Basic.Ground | ground2 | ||
| Modelica.Electrical.Analog.Sources.ConstantVoltage | battery | ||
| Blocks.SensorlessCtrl3phStateGraphNG | sensorlessCtrl3phPWM | Replacable (sensorless) BLDC controller | |
| Modelica.Blocks.Sources.Constant | motorVoltageCommand | Replaceable motor voltage command | |
| Modelica.Mechanics.Rotational.Components.BearingFriction | bearingFriction |