modelGrid
Model of a mechanical grid equivalent
Extends from OpenHPL.Icons.Pylon (Pylon icon), BaseClasses.Power2Torque (Converts a power signal to a torque in the rotational domain).
Information
Primary control
Network Power-Frequency Characteristic
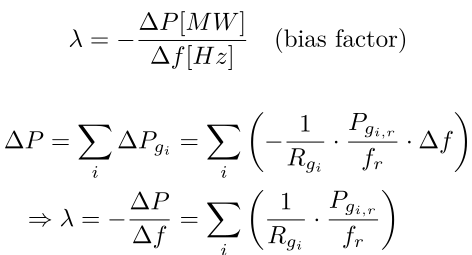
Self-regulation
Inductive loads like motors cause the system load to be slightly frequency dependent.
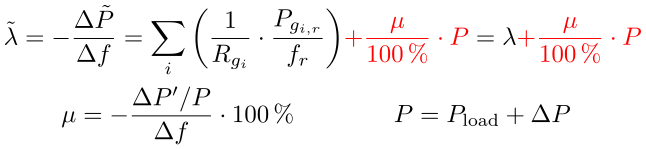
- μ [%/Hz]
- The self regulation effect of the load P [%/Hz]
- ΔP' [MW]
- The change in the power consumption of the loads because of the change in frequency Δf.
- P [MW]
- The value of the original load of the system plus the change ΔP due to the change in frequency.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Frequency | f_nom (from TorqueEquation) | data.f_grid/(p/2) | Nominal mechanical rotational frequency |
| Electrical | |||
| SI.Power | Pgrid | 1000000000 | Active power capacity of the grid |
| Boolean | useLambda | false | If checked, specify Lambda, otherwise the droop Rgrid is used |
| Types.Lambda | Lambda | Pgrid/(Rgrid*data.f_0*data.f_grid) | Network Power-Frequency Characteristic (bias factor) |
| SI.PerUnit | Rgrid | 0.1 | Equivalent droop setting of the grid |
| Real | mu | 0 | Self-regulation [%/Hz] |
| Mechanical | |||
| Boolean | useH (from TorqueEquation) | false | If checked, calculate the inertia from a given H value |
| SI.Power | Pmax (from TorqueEquation) | 100e6 | Maximum rated power (for torque limiting and H calculation) |
| SI.Time | H (from TorqueEquation) | 2.75 | Inertia constant H, typical 2s (high-head hydro) to 6s (gas or low-head hydro) production units |
| SI.MomentOfInertia | J (from TorqueEquation) | 2e5 | Moment of inertia of the unit (GD2/4) |
| Integer | p (from TorqueEquation) | 12 | Number of poles for mechanical speed calculation (Not pole pairs!) |
| SI.Power | Ploss (from TorqueEquation) | 0 | Friction losses of the unit at nominal speed |
| Initialization | |||
| SI.PerUnit | f_0 (from TorqueEquation) | 1 | Initial speed of the unit |
| Boolean | enable_nomSpeed (from TorqueEquation) | false | If checked, unit runs at fixed speed f_0 |
| Boolean | fixed_iniSpeed (from TorqueEquation) | false | If checked, unit initialises with fixed speed. When connecting several units mechanically only one can be fixed. |
| I/O › Inputs | |||
| Boolean | enable_f_in (from TorqueEquation) | false | If checked, get a connector for speed input |
| I/O › Outputs | |||
| Boolean | enable_w (from TorqueEquation) | false | If checked, get a connector for angular velocity output |
| Boolean | enable_f (from TorqueEquation) | false | If checked, get a connector for speed output |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput | f (from TorqueEquation) | Speed output of the unit [pu] | |
| Modelica.Blocks.Interfaces.RealOutput | w (from TorqueEquation) | Mechanical angular velocity output of the unit [rad/s] | |
| Modelica.Mechanics.Rotational.Interfaces.Flange_b | flange (from TorqueEquation) | Flange of right shaft | |
| Modelica.Blocks.Interfaces.RealInput | f_in (from TorqueEquation) | Speed input of the unit [pu] | |
| Modelica.Blocks.Interfaces.RealInput | Pload | Electrical load power demand |