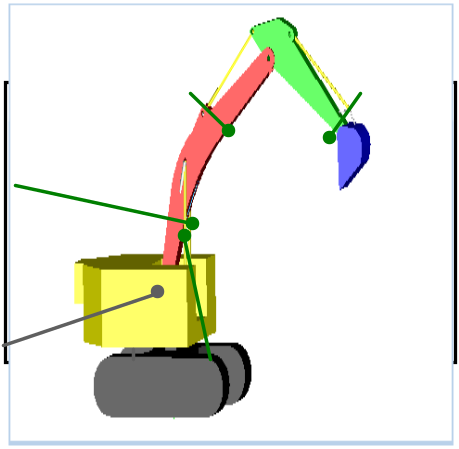
modelMechanicsBody_noFriction
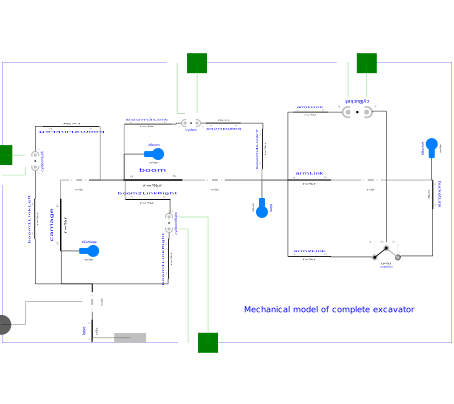
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Initialization › Swing | |||
| Types.RevoluteInit | swing_initType | Types.RevoluteInit.Free | Type of initialization (defines usage of start values below) |
| SI.Angle | swing_phi_start | 0 | Initial value of rotation angle phi (fixed or guess value) |
| SI.AngularVelocity | swing_w_start | 0 | Initial value of relative angular velocity w = der(phi) |
| SI.AngularAcceleration | swing_a_start | 0 | Initial value of relative angular acceleration a = der(w) |
| Initialization › Boom | |||
| Types.RevoluteInit | boom_initType | Types.RevoluteInit.Free | Type of initialization (defines usage of start values below) |
| SI.Angle | boom_phi_start | 0 | Initial value of rotation angle phi (fixed or guess value) |
| SI.AngularVelocity | boom_w_start | 0 | Initial value of relative angular velocity w = der(phi) |
| SI.AngularAcceleration | boom_a_start | 0 | Initial value of relative angular acceleration a = der(w) |
| Initialization › Arm | |||
| Types.RevoluteInit | arm_initType | Types.RevoluteInit.Free | Type of initialization (defines usage of start values below) |
| SI.Angle | arm_phi_start | 0 | Initial value of rotation angle phi (fixed or guess value) |
| SI.AngularVelocity | arm_w_start | 0 | Initial value of relative angular velocity w = der(phi) |
| SI.AngularAcceleration | arm_a_start | 0 | Initial value of relative angular acceleration a = der(w) |
| Initialization › Bucket | |||
| Types.RevoluteInit | bucket_initType | Types.RevoluteInit.Free | Type of initialization (defines usage of start values below) |
| SI.Angle | bucket_phi_start | 0 | Initial value of rotation angle phi (fixed or guess value) |
| SI.AngularVelocity | bucket_w_start | 0 | Initial value of relative angular velocity w = der(phi) |
| SI.AngularAcceleration | bucket_a_start | 0 | Initial value of relative angular acceleration a = der(w) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Rotational.Interfaces.Flange_a | swingFlange | input connector for rotation of swing function revolute joint | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | cylBoomRightBase | flange a of force in cylinder 1 (between carriage and boom) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | cylBoomRightRod | flange b of force in cylinder 1 (between carriage and boom ) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | cylBoomLeftBase | ||
| Modelica.Mechanics.Translational.Interfaces.Flange_a | cylBoomLeftRod | ||
| Modelica.Mechanics.Translational.Interfaces.Flange_b | cylArmBase | flange a of force in cylinder 2 (between boom and arm) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_a | cylArmRod | flange b of force in cylinder 2 (between boom and arm) | |
| Modelica.Mechanics.Translational.Interfaces.Flange_b | cylBucketBase | ||
| Modelica.Mechanics.Translational.Interfaces.Flange_a | cylBucketRod | ||
| MB.Interfaces.Frame_a | baseFrame |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| MB.World | world | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | swingRevolute | revolute joint (plus motor) representing the swing function | |
| Modelica.Mechanics.MultiBody.Joints.Revolute | boomRevolute | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | armRevolute | ||
| Modelica.Mechanics.MultiBody.Joints.Revolute | bucketRevolute | ||
| MB.Joints.Assemblies.JointRRR | jointRRR1 | ||
| MB.Forces.LineForceWithMass | cylBoomRight | hydraulic force in cylinder 1 (between carriage and boom) | |
| MB.Forces.LineForceWithMass | cylBoomLeft | hydraulic force in cylinder 1 (between carriage and boom) | |
| MB.Forces.LineForceWithMass | cylArm | hydraulic force in cylinder 2 (between boom and arm) | |
| MB.Forces.LineForceWithMass | cylBucket | hydraulic force in cylinder 2 (between boom and arm) | |
| MB.Parts.FixedTranslation | base | object model for the base of the excavator | |
| MB.Parts.FixedTranslation | carriage | object model for the carriage of the excavator | |
| MB.Parts.FixedTranslation | boom | object model for the boom of the excavator | |
| MB.Parts.FixedTranslation | boom1LinkRight | from swing motor to lifting cylinder cap side pivot | |
| MB.Parts.FixedTranslation | boom1LinkLeft | from swing motor to lifting cylinder cap side pivot | |
| MB.Parts.FixedTranslation | boom2LinkRight | from boom-lift pivot to lifting cylinder rod side pivot | |
| MB.Parts.FixedTranslation | boom2LinkLeft | from boom-lift pivot to lifting cylinder rod side pivot | |
| MB.Parts.FixedTranslation | boom3Link | from boom-lift pivot to arm cylinder cap side pivot | |
| MB.Parts.FixedTranslation | boom4LinkX | ||
| MB.Parts.FixedTranslation | boom4LinkY | ||
| MB.Parts.FixedTranslation | armLink | object model for the arm of the excavator | |
| MB.Parts.FixedTranslation | arm1Link | object model for the arm of the excavator | |
| MB.Parts.FixedTranslation | arm2Link | object model for the arm of the excavator | |
| MB.Parts.FixedTranslation | bucketLink | ||
| MB.Parts.Body | bCarriage | mass/inertia properties for carriage | |
| MB.Parts.Body | bBoom | mass/inertia properties for boom | |
| MB.Parts.Body | bArm | mass/inertia properties for arm | |
| MB.Parts.Body | bBucket | mass/inertia properties for arm |