modelMultiDomainMotorStartUpComparison

Validation example for the variable speed drive driven ALL-IN-ONE motor

Extends from Modelica.Icons.Example (Icon for runnable examples), OpenIMDML.Examples.BaseClasses.ValidationPartial3 (Partial model 3 for validation purposes).

Information

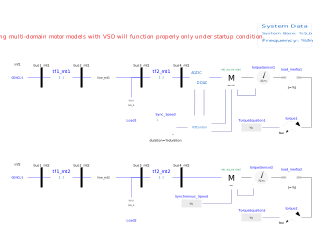
The example MultiDomainMotorStartUpComparison contains two separate systems meant for comparison. The top system is an ALL-IN-ONE multi-domain induction motor model controlled by a Variable Speed Drive while the bottom system is the same example but with no VSD controller. The purpose of this example is to compare the startup current magnitude of both systems and to point out one of the major benefits of using a VSD in the startup process. Starting an induction motor from a halt condition generates a peak starting current in the motor which is detrimental to the stability of the electrical system and to the magnitization coils of the machine itself. The user can compare both startup currents in one example and confirm that the startup current magnitude in the VSD example is substantially smaller in comparison to the non VSD example.

The Volts/Hertz scalar variable speed drive model is based on paper Del Rosso, A. D., Mariano Anello, and E. Spittle. "Stability Assessment of Isolated Power Systems with Large Induction Motor Drives." 2006 IEEE/PES Transmission & Distribution Conference and Exposition: Latin America. IEEE, 2006.

Simulate the system for 10 seconds. Variables of interest and comparison are:

  • motor.motor.Imag vs motorVSD.motor.Imag
  • motor.motor.s vs motorVSD.motor.s
  • motor.motor.wr vs motorVSD.motor.wr
  • motor.motor.P vs motorVSD.motor.P
  • motor.motor.Q vs motorVSD.motor.Q
  • VfController.m
  • VfController.we

Parameters

TypeNameDefaultDescription
RealRo0.1

Components

TypeNameDefaultDescription
OpenIPSL.Electrical.Machines.PSSE.GENCLSinf1 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus1_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus2_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PwLineline_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus3_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus4_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PSAT.TwoWindingTransformertf1_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PSAT.TwoWindingTransformertf2_mt1 (from ValidationPartial3)
OpenIPSL.Electrical.Loads.PSAT.PQLoad1 (from ValidationPartial3)
OpenIPSL.Electrical.SystemBaseSysData (from ValidationPartial3)
OpenIPSL.Electrical.Machines.PSSE.GENCLSinf2 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus1_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus2_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PwLineline_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus3_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Buses.Busbus4_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PSAT.TwoWindingTransformertf1_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Branches.PSAT.TwoWindingTransformertf2_mt2 (from ValidationPartial3)
OpenIPSL.Electrical.Loads.PSAT.PQLoad2 (from ValidationPartial3)
OpenIPSL.Types.PerUnitTorqVSD
OpenIPSL.Types.PerUnitTorq
Modelica.Units.SI.AngularVelocitysync_speed
Controls.VariableSpeedDrive.PowerElectronics.AC2DCandDC2ACAC2DC_and_DC2AC
Controls.VariableSpeedDrive.ControllerLogic.VoltsHertzControllerVfController
Modelica.Mechanics.Rotational.Sensors.TorqueSensortorqueSensor1
Modelica.Mechanics.Rotational.Sources.Torquetorque1
Modelica.Mechanics.Rotational.Components.Inertiaload_inertia1
Modelica.Blocks.Sources.RealExpressionTorqueEquation1
Modelica.Blocks.Sources.RampSync_Speed
Modelica.Mechanics.Rotational.Sensors.TorqueSensortorqueSensor2
Modelica.Mechanics.Rotational.Sources.Torquetorque2
Modelica.Mechanics.Rotational.Components.Inertiaload_inertia2
Modelica.Blocks.Sources.RealExpressionTorqueEquation2
Modelica.Blocks.Sources.RealExpressionSynchronous_Speed
MultiDomain.Motors.MD_All_In_One_ThreePhaseMotormotorVSD
MultiDomain.Motors.MD_All_In_One_ThreePhaseMotormotor