modelPIDGovernorDU
GE GGOV1DU General Governor Frequency Controller
Information
The following documentation is adapted from [PSSE-Models], chapter 7.13:
Frequency control system for the general purpose Turbine/Governor models GGOV1DU. Note that four feedback variables can be chosen for the droop control. If the turbine is set to be isochronous, it is necessary to set the permanent droop to zero.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | Rselect | 1 | Feedback signal for governor droop |
| Types.PerUnit | R | 0.04 | Permanent droop |
| Types.Time | T_pelec | 1 | Electrical power transducer time constant |
| Types.PerUnit | maxerr | 0.05 | Maximum value for speed error signal |
| Types.PerUnit | minerr | -0.05 | Minimum value for speed error signal |
| Types.PerUnit | Kpgov | 10 | Governor proportional gain |
| Types.TimeAging | Kigov | 2 | Governor integral gain |
| Types.Time | Kdgov | 0 | Governor derivative gain |
| Types.Time | Tdgov | 1 | Governor derivative controller time constant |
| Types.PerUnit | Kturb | 1.5 | Turbine gain |
| Types.PerUnit | Wfnl | 0.2 | No load fuel flow |
| Types.TimeAging | Kimw | 0 | Power controller (reset) gain |
| Types.PerUnit | db | 0 | Speed governor deadband |
| Types.PerUnit | Dm | 0 | Mechanical damping coefficient |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
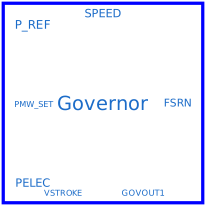
| Modelica.Blocks.Interfaces.RealInput | PELEC | Machine electrical power (pu) | |
| Modelica.Blocks.Interfaces.RealInput | PMW_SET | Supervisory Load Controller Setpoint | |
| Modelica.Blocks.Interfaces.RealInput | P_REF | ||
| Modelica.Blocks.Interfaces.RealInput | SPEED | Machine speed deviation from nominal (pu) | |
| Modelica.Blocks.Interfaces.RealInput | VSTROKE | Valve Stroke | |
| Modelica.Blocks.Interfaces.RealInput | GOVOUT1 | Governor Output before Limiter | |
| Modelica.Blocks.Interfaces.RealOutput | FSRN |
Components
| Type | Name | Default | Description |
|---|---|---|---|
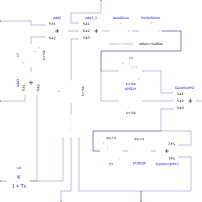
| Modelica.Blocks.Math.Gain | KPGOV | ||
| Modelica.Blocks.Continuous.Integrator | s2 | ||
| Modelica.Blocks.Continuous.Derivative | s1 | ||
| Modelica.Blocks.Math.Add3 | GovernorPID | ||
| Modelica.Blocks.Nonlinear.DeadZone | deadZone | ||
| Modelica.Blocks.Nonlinear.Limiter | limiterSerror | ||
| Modelica.Blocks.Math.Add3 | add3_2 | ||
| Modelica.Blocks.Math.Gain | r | Permanent droop | |
| Modelica.Blocks.Math.Add | add2 | ||
| Modelica.Blocks.Continuous.LimIntegrator | s7 | Power controller | |
| Modelica.Blocks.Math.Add | add3 | ||
| OpenIPSL.NonElectrical.Continuous.SimpleLag | s0 | ||
| Modelica.Blocks.Math.Gain | KPGOV1 | ||
| Modelica.Blocks.Math.Add | LoadlimiterPI2 | ||
| OpenIPSL.Electrical.Controls.PSSE.TG.BaseClasses.GGOV1.R_select | rSELECT |
Revisions
Reference |
PSS®E Models |
Last update |
2020-11-22 |
Author |
|
Contact |