modelVoltsHertzController
Extends from OpenIPSL.Electrical.Essentials.pfComponent (Partial model containing all the parameters for entering power flow data).
Information
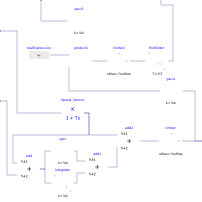
The VoltsHertzController component represents the controller logic for the variable speed drive. The volts hertz control is a simple and widely used method for controlling the speed of an AC induction motor by adjusting the voltage and frequency supplied to the motor at a constant ratio.
The model has three inputs and two output connectors. The W_ref input connector represents the reference synchronous speed that is user defined, motor_speed input is the motor speed that is generated by the motor model, and the Vc input is the capacitor voltage value from the AC2DCandDC2AC component. The m output is the PWM modulation index, and the we output is the synchronous speed that is used in the controllable motor model.
The modelling of such devices is based, mainly, on the following reference:
- Panasetsky: Variable Speed Drive Modeling" [Panasetsky2016],
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Power flow data | |||
| Types.ApparentPower | S_b (from pfComponent) | SysData.S_b | System base power |
| Types.Voltage | V_b (from pfComponent) | 400e3 | Base voltage of the bus |
| Types.Frequency | fn (from pfComponent) | SysData.fn | System frequency |
| Types.ActivePower | P_0 (from pfComponent) | 1e6 | Initial active power |
| Types.ReactivePower | Q_0 (from pfComponent) | 0 | Initial reactive power |
| Types.PerUnit | v_0 (from pfComponent) | 1 | Initial voltage magnitude |
| Types.Angle | angle_0 (from pfComponent) | 0 | Initial voltage angle |
| Boolean | displayPF (from pfComponent) | false | Display power flow: |
| Parameter mask | |||
| Boolean | enableS_b (from pfComponent) | false | Enable S_b in parameter list |
| Boolean | enableV_b (from pfComponent) | false | Enable V_b in parameter list |
| Boolean | enablefn (from pfComponent) | false | Enable fn in parameter list |
| Boolean | enableP_0 (from pfComponent) | false | Enable P_0 in parameter list |
| Boolean | enableQ_0 (from pfComponent) | false | Enable Q_0 in parameter list |
| Boolean | enablev_0 (from pfComponent) | false | Enable v_0 in parameter list |
| Boolean | enableangle_0 (from pfComponent) | false | Enable angle_0 in parameter list |
| Boolean | enabledisplayPF (from pfComponent) | false | Enable displayPF in parameter list |
| VSD project specifics | |||
| Modelica.Units.SI.Frequency | f_max | 80 | Maximum input voltage frequency |
| Modelica.Units.SI.Frequency | f_min | 40 | Minimum input voltage frequency |
| Real | m0 | 0.1 | Initial PWM Modulation Value |
| Control Parameters | |||
| OpenIPSL.Types.Time | Tr | 0.01 | Time constant for speed sensor filter |
| Real | Kp | 5 | PI proportional gain |
| Real | Ki | 0.1 | PI integrator gain |
| Real | we_max | 2*pi*f_max | Maximum Synchronous Speed |
| Real | we_min | 2*pi*f_min | Minimum Synchronous Speed |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | motor_speed | Motor speed from motor model | |
| Modelica.Blocks.Interfaces.RealOutput | we | Synchronous speed | |
| Modelica.Blocks.Interfaces.RealOutput | m | PWM modulation index | |
| Modelica.Blocks.Interfaces.RealInput | Vc | Capacitor voltage value | |
| Modelica.Blocks.Interfaces.RealInput | W_ref | Synchronous speed reference |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| OpenIPSL.Electrical.SystemBase | SysData (from pfComponent) | Must add this line in all models | |
| OpenIPSL.NonElectrical.Continuous.SimpleLag | Speed_Sensor | ||
| Modelica.Blocks.Math.Add | add | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Modelica.Blocks.Continuous.Integrator | integrator | ||
| Modelica.Blocks.Math.Add | add1 | ||
| Modelica.Blocks.Math.Add | add2 | ||
| Modelica.Blocks.Math.Gain | gain1 | ||
| Real | Kf | 1/(2*pi*fn) | Gain value multiplied with input signal |
| Modelica.Blocks.Nonlinear.Limiter | limiter1 | ||
| Modelica.Blocks.Math.Gain | gain2 | ||
| Modelica.Blocks.Sources.RealExpression | realExpression | ||
| Modelica.Blocks.Math.Product | product1 | ||
| Modelica.Blocks.Continuous.FirstOrder | firstOrder |