modelPID_No_Windup
PID controller with no wind-up
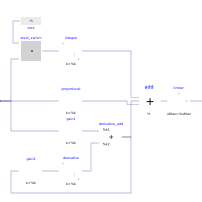
Extends from PI_No_Windup (PI controller with no wind-up).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Types.PerUnit | K_P (from PI_No_Windup) | Voltage regulator proportional gain | |
| Types.PerUnit | K_I (from PI_No_Windup) | Voltage regulator integral gain | |
| Types.PerUnit | V_RMAX (from PI_No_Windup) | Maximum regulator output | |
| Types.PerUnit | V_RMIN (from PI_No_Windup) | Minimum regulator output | |
| Types.PerUnit | y_start_int (from PI_No_Windup) | Initial output value | |
| Types.PerUnit | K_D | Voltage regulator derivative gain | |
| Types.Time | T_D | Voltage regulator derivative channel time constant |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Continuous.Integrator | integral (from PI_No_Windup) | ||
| Modelica.Blocks.Math.Gain | proportional (from PI_No_Windup) | ||
| Modelica.Blocks.Math.MultiSum | add (from PI_No_Windup) | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter (from PI_No_Windup) | ||
| Modelica.Blocks.Logical.Switch | reset_switch (from PI_No_Windup) | ||
| Modelica.Blocks.Sources.RealExpression | zero (from PI_No_Windup) | ||
| Modelica.Blocks.Math.Gain | gain1 | ||
| Modelica.Blocks.Math.Add | derivative_add | ||
| Modelica.Blocks.Continuous.Integrator | derivative | ||
| Modelica.Blocks.Math.Gain | gain2 |