modelLink
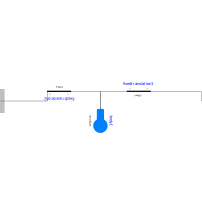
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Position | l | 1 | Length of the link |
| Position | lc | 0.5 | Distance from link L to the center of mass |
| Mass | m | 1 | Mass of the link |
| Inertia | J | 1 | Inertia of the link |
| Position | d | 0.1 | Diameter of the link, only for visualisation |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a | ||
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b | frame_b |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Parts.Body | body1 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedtranslation2 | ||
| Modelica.Mechanics.MultiBody.Parts.FixedTranslation | fixedtranslation1 |