blockBasic3phasePLL
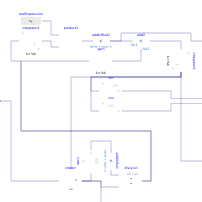
Extends from Modelica.Blocks.Interfaces.MIMO (Multiple Input Multiple Output continuous control block), Interfaces.w_theta (Signal output w and theta).
Information
The basic version of the three phase PLL assumes that a Clarke transformation is performed, then feeding the α- and β-component to this block.
Here a Park transformation on the inputs u[1..2] is applied, using the angle θ determined by the control loop.
The d- and the q-component are divided by the estimated amplitude to obtain an amplitude of 1.
Subsequently, the q-component is controlled to become 0, ie. determining the desired angle θ
as well as the frequency resp. angular velocity ω = 2 π f = w.
The output y[1] is a cosine signal in phase with the input u,
the output y[2] is a sine signal 90° phase shifted to y[1].
Result of the Clarke - Park - transformation can be inspected with u0, ud and uq.
Problems: especially a double-frequency ripple on the estimated frequency under distorted conditions, i.e. when the input signals contain not only a positive sequence but also a negative sequence and / or zero component. For symmterical components, see [Fortescue1918].
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | nin (from MIMO) | 1 | Number of inputs |
| Integer | nout (from MIMO) | 1 | Number of outputs |
| Real | A0 | 1 | Rated amplitude of input |
| SI.Frequency | f0 | 50 | Rated frequency |
| SI.AngularVelocity | wn | 0.25*2*pi*f0 | Natural angular velocity |
| Real | zeta | 0.5 | Damping ratio |
| Real | kp | 2*zeta*wn | Proportional gain |
| Real | ki | wn^2 | Integral gain |
| Real | epsilon | 0.001 | Avoid division by 0 |
| Real | lamda | 0 | Factor for adaptive integrator |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput[nin] | u (from MIMO) | Connector of Real input signals | |
| RealOutput[nout] | y (from MIMO) | Connector of Real output signals | |
| Modelica.Blocks.Interfaces.RealOutput | w (from w_theta) | Estimated angular velocity | |
| Modelica.Blocks.Interfaces.RealOutput | theta (from w_theta) | Estimated angle | |
| Modelica.Blocks.Interfaces.RealOutput[2] | udq | ud, uq |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Electrical.Machines.SpacePhasors.Blocks.Rotator | rotator | ||
| Modelica.Blocks.Math.Division | division | ||
| Modelica.Blocks.Math.Abs | abs1 | ||
| Auxilliary.AddOffset | addOffset | ||
| Modelica.Blocks.Continuous.Integrator | integrator1 | ||
| Auxilliary.AddOffset | addOffset1 | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Auxilliary.Add | add2 | ||
| Modelica.Blocks.Continuous.Integrator | integrator2 | ||
| Modelica.Blocks.Math.Sin | sin | ||
| Modelica.Blocks.Math.Cos | cos | ||
| Modelica.Blocks.Math.Product | product1 | ||
| Modelica.Blocks.Sources.RealExpression | realExpression |