blockMotorBlock
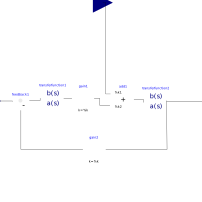
Extends from Modelica.Blocks.Interfaces.SISO (Single Input Single Output continuous control block).
Information
General
This blocks models the transfer function of a permanent magnet dc motor.
Implementation
Given the mathematical equation for the transfer function:
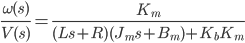
However, for this block mechanical disturbance effects are added as an input.
Notes
- This block has causality predetermined
- The output is speed and the input voltage.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | R | 0.385 | Armature Resistance |
| Real | L | 0.000006 | Armature Inductance |
| Real | km | 7.83 | Torque Constant |
| Real | J | 0.0000000153 | Rotor Inertia |
| Real | B | 0 | Damping constant |
| Real | kb | 7.83 | Back emf constant |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal | |
| Modelica.Blocks.Interfaces.RealInput | realinput1 |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Math.Add | add1 | ||
| Modelica.Blocks.Math.Gain | gain1 | ||
| Modelica.Blocks.Continuous.TransferFunction | transferfunction1 | ||
| Modelica.Blocks.Math.Feedback | feedback1 | ||
| Modelica.Blocks.Math.Gain | gain2 | ||
| Modelica.Blocks.Continuous.TransferFunction | transferfunction2 |